Add touch sensor for estimating the surface contact stresses from the SDF.
PiperOrigin-RevId: 758556339
Change-Id: Ib56d76fab084b530fd68d61a29294cb6f1d05f3f
This commit is contained in:
 Alessio Quaglino
committed by
Copybara-Service
Copybara-Service
parent
23865c7491
commit
2386dfd7da
+65
-1
@@ -9,6 +9,9 @@ plugins](https://mujoco.readthedocs.io/en/latest/programming/extension.html#engi
|
||||
- [Illustration of foveal deformation](#illustration-of-foveal-deformation)
|
||||
- [Illustration combining resolution, fields-of-view and foveal deformation](#illustration-combining-resolution-fields-of-view-and-foveal-deformation)
|
||||
|
||||
- [Touch Stress](#touch-stress)
|
||||
- [Example model with analytical SDF](#example-model-with-analytical-sdf)
|
||||
|
||||
## [Touch Grid](touch_grid.h)
|
||||
|
||||
This sensor aggregates contact forces into "taxels": a rectangular array of pixel-like elements.
|
||||
@@ -23,7 +26,7 @@ The output of the sensor is a stack of 1 to 6 "touch images" corresponding to fo
|
||||
and torques in the frame of the sensor. Forces and torques are in the in [z, x,
|
||||
y] order, corresponding to the ordering in contact frames: [normal, tangent,
|
||||
tangent] and [torsional, rolling, rolling]. Each "taxel" corresponds to an angular bin
|
||||
in spherical coordinates, and aggregates all the forces occuring inside this bin, which occur
|
||||
in spherical coordinates, and aggregates all the forces occurring inside this bin, which occur
|
||||
between the body in which the sensor's site is defined and any other body.
|
||||
|
||||
The sensor is parametrized by 6 numbers:
|
||||
@@ -84,3 +87,64 @@ See [touch_grid.xml](../../model/plugin/sensor/touch_grid.xml) to play with the
|
||||
### Illustration combining resolution, fields-of-view and foveal deformation
|
||||
|
||||
[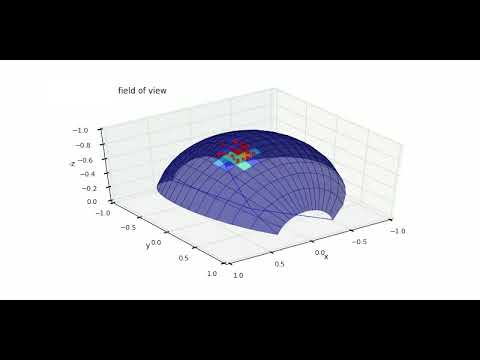](https://www.youtube.com/watch?v=YScjmR8LwQI)
|
||||
|
||||
## [Touch Stress](touch_stress.h)
|
||||
|
||||
This sensor is based on similar concepts and parametrization as the `touch_grid`,
|
||||
while overcoming some of its limitations. In particular, the `touch_grid` can
|
||||
only provide sparse information, depending on the number of contact points
|
||||
generated. The `touch_stress` sensor can instead generate a high-resolution
|
||||
touch image. In order to do this, it requires a signed distance function (SDF)
|
||||
of the object that is in contact with the sensor. This is handled internally for
|
||||
primitives or it must be declared explicitly in the model using SDF plugins.
|
||||
|
||||
There is one important difference with respect to the `touch_grid`: in this case,
|
||||
the force is computed in the local taxel frame and not in the frame of the sensor.
|
||||
This allows for a more intuitive interpretation of normal and tangential stresses,
|
||||
as shown in the images below.
|
||||
|
||||
Note that in this case, the absolute values of the stresses reported by the
|
||||
sensor are unrelated to the contact forces. They are purely based on geometric
|
||||
and kinematic considerations, i.e. the SDF for the normal stress and the sliding
|
||||
velocity for the tangential contributions.
|
||||
|
||||
### Example model with analytical SDF
|
||||
|
||||
```xml
|
||||
<extension>
|
||||
<plugin plugin="mujoco.sdf.gear">
|
||||
<instance name="gear">
|
||||
<config key="alpha" value="0"/>
|
||||
</instance>
|
||||
</plugin>
|
||||
<plugin plugin="mujoco.sensor.touch_stress">
|
||||
<instance name="touch_stress">
|
||||
<config key="size" value="37 37"/>
|
||||
<config key="fov" value="45 45"/>
|
||||
<config key="gamma" value="0"/>
|
||||
<config key="nchannel" value="3"/>
|
||||
</instance>
|
||||
</plugin>
|
||||
...
|
||||
<asset>
|
||||
<mesh name="gear">
|
||||
<plugin instance="gear"/>
|
||||
</mesh>
|
||||
</asset>
|
||||
...
|
||||
<worldbody>
|
||||
<geom type="sdf" name="gear" mesh="gear">
|
||||
<plugin instance="gear"/>
|
||||
</geom>
|
||||
...
|
||||
<sensor>
|
||||
<plugin instance="touch_stress" objtype="site" objname="touch_site"/>
|
||||
</sensor>
|
||||
</extension>
|
||||
```
|
||||
The images below show a static sphere over a gear described by an analytic SDF
|
||||
and the same sphere dragged along the x and y axes.
|
||||
|
||||
<img src="images/normal.png" style="width: 300px;"/>
|
||||
<img src="images/tangential1.png" style="width: 300px;"/>
|
||||
<img src="images/tangential2.png" style="width: 300px;"/>
|
||||
|
||||
Reference in New Issue
Block a user