Improve touch_grid sensor documentation.
PiperOrigin-RevId: 528473107
Change-Id: I2fecc10667b1b94a4b2b32653685f0a6d9da4ba9
This commit is contained in:
 Kevin Zakka
committed by
Copybara-Service
Copybara-Service
parent
ced9e0872f
commit
4d2bf636ea
+27
-13
@@ -1,13 +1,19 @@
|
|||||||
# Sensor Plugins
|
# Sensor Plugins
|
||||||
|
|
||||||
Custom sensors implemented as [engine plugins](https://mujoco.readthedocs.io/en/latest/programming/extension.html#engine-plugins).
|
Custom sensors implemented as [engine
|
||||||
|
plugins](https://mujoco.readthedocs.io/en/latest/programming/extension.html#engine-plugins).
|
||||||
|
|
||||||
## Touch Grid
|
- [Touch Grid](#touch-grid)
|
||||||
|
- [Example model](#example-model)
|
||||||
|
- [Illustration of fields-of-view in spherical coordinates](#illustration-of-fields-of-view-in-spherical-coordinates)
|
||||||
|
- [Illustration of foveal deformation](#illustration-of-foveal-deformation)
|
||||||
|
- [Illustration combining resolution, fields-of-view and foveal deformation](#illustration-combining-resolution-fields-of-view-and-foveal-deformation)
|
||||||
|
|
||||||
|
## [Touch Grid](touch_grid.h)
|
||||||
|
|
||||||
This sensor aggregates contact forces into "taxels": a rectangular array of pixel-like elements.
|
This sensor aggregates contact forces into "taxels": a rectangular array of pixel-like elements.
|
||||||
|
|
||||||
|
A `touch_grid` sensor is associated with a site and senses contact forces and
|
||||||
A `touch grid` sensor is associated with a site and senses contact forces and
|
|
||||||
torques between the site's parent body and all other bodies. The site's frame
|
torques between the site's parent body and all other bodies. The site's frame
|
||||||
determines the orientation of the sensor with the same convention used for
|
determines the orientation of the sensor with the same convention used for
|
||||||
cameras and lights: the sensor points in the frame's **negative-z** direction,
|
cameras and lights: the sensor points in the frame's **negative-z** direction,
|
||||||
@@ -16,7 +22,7 @@ so the x and y axes correspond to horizontal and vertical, respectively.
|
|||||||
The output of the sensor is a stack of 1 to 6 "touch images" corresponding to forces
|
The output of the sensor is a stack of 1 to 6 "touch images" corresponding to forces
|
||||||
and torques in the frame of the sensor. Forces and torques are in the in [z, x,
|
and torques in the frame of the sensor. Forces and torques are in the in [z, x,
|
||||||
y] order, corresponding to the ordering in contact frames: [normal, tangent,
|
y] order, corresponding to the ordering in contact frames: [normal, tangent,
|
||||||
tangent] and [torsional, rolling, rolling]. Each "taxel" codderponds to an angular bin
|
tangent] and [torsional, rolling, rolling]. Each "taxel" corresponds to an angular bin
|
||||||
in spherical coordinates, and aggregates all the forces occuring inside this bin, which occur
|
in spherical coordinates, and aggregates all the forces occuring inside this bin, which occur
|
||||||
between the body in which the sensor's site is defined and any other body.
|
between the body in which the sensor's site is defined and any other body.
|
||||||
|
|
||||||
@@ -53,22 +59,30 @@ deformation parameters. These parameters are passed as plugin config attributes:
|
|||||||
|
|
||||||
Note the following:
|
Note the following:
|
||||||
|
|
||||||
- The dimensionality of the sensor output is `nchannel * size_x *size_y`.
|
- The dimensionality of the sensor output is `nchannel * size_x *size_y`.
|
||||||
- `objtype="site" objname="touch"` specify that the sensor is associated with
|
- `objtype="site" objname="touch"` specify that the sensor is associated with a
|
||||||
a site, and the name of the specific site.
|
site, and the name of the specific site.
|
||||||
- Field-of-view angles are always in degrees, disregarding the `<compiler>`
|
- Field-of-view angles are always in degrees, disregarding the `<compiler>`
|
||||||
"angle" directive.
|
"angle" directive.
|
||||||
|
|
||||||
### Illustration of fields-of-view in spherical coordinates:
|
### Example model
|
||||||
|
|
||||||
|
<a href="https://youtu.be/0LOJ3WMnqeA" target="_blank">
|
||||||
|
<img src="http://img.youtube.com/vi/0LOJ3WMnqeA/hqdefault.jpg" alt="Watch the video" width="560" height="315"/>
|
||||||
|
</a>
|
||||||
|
|
||||||
|
See [touch_grid.xml](../../model/plugin/touch_grid.xml) to play with the model above.
|
||||||
|
|
||||||
|
### Illustration of fields-of-view in spherical coordinates
|
||||||
|
|
||||||
<img src="images/30-30.png" style="width: 300px;"/>
|
<img src="images/30-30.png" style="width: 300px;"/>
|
||||||
<img src="images/180-30.png" style="width: 300px;"/>
|
<img src="images/180-30.png" style="width: 300px;"/>
|
||||||
<img src="images/180-90.png" style="width: 300px;"/>
|
<img src="images/180-90.png" style="width: 300px;"/>
|
||||||
|
|
||||||
### Illustration of foveal deformation:
|
### Illustration of foveal deformation
|
||||||
|
|
||||||

|

|
||||||
|
|
||||||
### Illustration combining resolution, fields-of-view and foveal deformation:
|
### Illustration combining resolution, fields-of-view and foveal deformation
|
||||||
|
|
||||||
[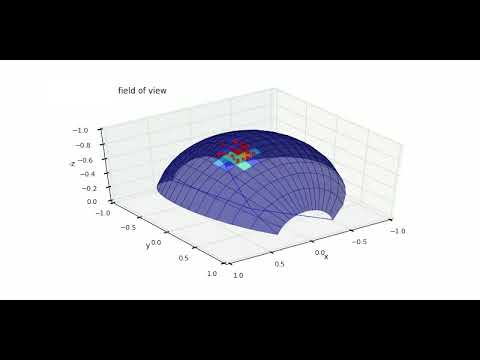](https://www.youtube.com/watch?v=YScjmR8LwQI)
|
[](https://www.youtube.com/watch?v=YScjmR8LwQI)
|
||||||
|
|||||||
Reference in New Issue
Block a user