Added touch grid sensor plugin.
PiperOrigin-RevId: 527512624
Change-Id: I0f316eb6eb2c52472abbec484e5538b66ba2e82e
This commit is contained in:
 Yuval Tassa
committed by
Copybara-Service
Copybara-Service
parent
139328f86e
commit
b397b3123e
@@ -152,12 +152,14 @@ jobs:
|
|||||||
if: ${{ runner.os != 'Windows' }}
|
if: ${{ runner.os != 'Windows' }}
|
||||||
working-directory: build
|
working-directory: build
|
||||||
run: mkdir -p ${{ matrix.tmpdir }}/mujoco_install/mujoco_plugin &&
|
run: mkdir -p ${{ matrix.tmpdir }}/mujoco_install/mujoco_plugin &&
|
||||||
cp lib/libelasticity.* ${{ matrix.tmpdir }}/mujoco_install/mujoco_plugin
|
cp lib/libelasticity.* ${{ matrix.tmpdir }}/mujoco_install/mujoco_plugin &&
|
||||||
|
cp lib/libsensor.* ${{ matrix.tmpdir }}/mujoco_install/mujoco_plugin
|
||||||
- name: Copy plugins (Windows)
|
- name: Copy plugins (Windows)
|
||||||
if: ${{ runner.os == 'Windows' }}
|
if: ${{ runner.os == 'Windows' }}
|
||||||
working-directory: build
|
working-directory: build
|
||||||
run: mkdir -p ${{ matrix.tmpdir }}/mujoco_install/mujoco_plugin &&
|
run: mkdir -p ${{ matrix.tmpdir }}/mujoco_install/mujoco_plugin &&
|
||||||
cp bin/Release/elasticity.dll ${{ matrix.tmpdir }}/mujoco_install/mujoco_plugin
|
cp bin/Release/elasticity.dll ${{ matrix.tmpdir }}/mujoco_install/mujoco_plugin &&
|
||||||
|
cp bin/Release/sensor.dll ${{ matrix.tmpdir }}/mujoco_install/mujoco_plugin
|
||||||
- name: Configure samples
|
- name: Configure samples
|
||||||
working-directory: sample
|
working-directory: sample
|
||||||
run: >
|
run: >
|
||||||
|
|||||||
@@ -81,6 +81,7 @@ target_include_directories(
|
|||||||
)
|
)
|
||||||
|
|
||||||
add_subdirectory(plugin/elasticity)
|
add_subdirectory(plugin/elasticity)
|
||||||
|
add_subdirectory(plugin/sensor)
|
||||||
add_subdirectory(src/engine)
|
add_subdirectory(src/engine)
|
||||||
add_subdirectory(src/user)
|
add_subdirectory(src/user)
|
||||||
add_subdirectory(src/xml)
|
add_subdirectory(src/xml)
|
||||||
|
|||||||
@@ -2,6 +2,21 @@
|
|||||||
Changelog
|
Changelog
|
||||||
=========
|
=========
|
||||||
|
|
||||||
|
Upcoming version (not yet released)
|
||||||
|
-----------------------------------
|
||||||
|
|
||||||
|
Plugins
|
||||||
|
^^^^^^^
|
||||||
|
|
||||||
|
.. youtube:: hqIMTNGaLF4
|
||||||
|
:align: right
|
||||||
|
:width: 240px
|
||||||
|
|
||||||
|
- Added touch-grid sensor plugin. See `documentation <https://github.com/deepmind/mujoco/blob/main/plugin/sensor/README.md>`_
|
||||||
|
for details, and associated `touch_grid.xml <https://github.com/deepmind/mujoco/blob/main/model/plugin/touch_grid.xml>`_
|
||||||
|
example model. The plugin includes `in-scene visualisation <https://youtu.be/0LOJ3WMnqeA>`_.
|
||||||
|
|
||||||
|
|
||||||
Version 2.3.5 (April 25, 2023)
|
Version 2.3.5 (April 25, 2023)
|
||||||
------------------------------
|
------------------------------
|
||||||
|
|
||||||
|
|||||||

Binary file not shown.
|
After Width: | Height: | Size: 195 B |
@@ -0,0 +1,54 @@
|
|||||||
|
<mujoco model="touchtest">
|
||||||
|
<compiler autolimits="true"/>
|
||||||
|
|
||||||
|
<extension>
|
||||||
|
<plugin plugin="mujoco.sensor.touch_grid"/>
|
||||||
|
</extension>
|
||||||
|
|
||||||
|
<asset>
|
||||||
|
<texture name="grid" type="2d" builtin="checker" rgb1=".1 .2 .3" rgb2=".2 .3 .4" width="300" height="300" mark="edge" markrgb=".2 .3 .4"/>
|
||||||
|
<material name="grid" texture="grid" texrepeat="3 1" texuniform="true"/>
|
||||||
|
<hfield file="a.png" size="0.2 0.2 0.02 0.015"/>
|
||||||
|
</asset>
|
||||||
|
|
||||||
|
<visual>
|
||||||
|
<headlight ambient=".7 .7 .7" diffuse=".2 .2 .2" specular="0.1 0.1 0.1"/>
|
||||||
|
<map znear="0.01"/>
|
||||||
|
<scale contactwidth=".02" contactheight=".5"/>
|
||||||
|
</visual>
|
||||||
|
|
||||||
|
<default>
|
||||||
|
<geom friction="0.4" solimp="0 0.95 0.02"/>
|
||||||
|
</default>
|
||||||
|
|
||||||
|
<statistic center="0 0 1" extent="1" meansize=".1"/>
|
||||||
|
|
||||||
|
<worldbody>
|
||||||
|
<light pos="1 0 .3" dir="-1 0 -.3"/>
|
||||||
|
<light pos="-1 0 .3" dir="1 0 -.3"/>
|
||||||
|
<geom name="floor" pos="0 0 -0.01" type="plane" size="1 1 .01"/>
|
||||||
|
|
||||||
|
<geom name="a" type="hfield" hfield="a" rgba=".5 .5 .7 1"/>
|
||||||
|
|
||||||
|
<body name="ball" pos="0 0 1">
|
||||||
|
<joint name="x" type="slide" axis="1 0 0" damping="1"/>
|
||||||
|
<joint name="y" type="slide" axis="0 1 0" damping="1"/>
|
||||||
|
<joint name="z" type="slide" axis="0 0 1"/>
|
||||||
|
<joint name="rx" axis="1 0 0" springdamper="0.2 1"/>
|
||||||
|
<joint name="ry" axis="0 1 0" springdamper="0.2 1"/>
|
||||||
|
<geom type="ellipsoid" size=".3 .5 .1" mass="0.1" rgba=".5 .5 .5 .3"/>
|
||||||
|
<site name="touch" pos="0 0 .1"/>
|
||||||
|
</body>
|
||||||
|
</worldbody>
|
||||||
|
|
||||||
|
<sensor>
|
||||||
|
<plugin name="touch" plugin="mujoco.sensor.touch_grid" objtype="site" objname="touch">
|
||||||
|
<config key="size_x" value="7"/>
|
||||||
|
<config key="size_y" value="7"/>
|
||||||
|
<config key="fov_x" value="45"/>
|
||||||
|
<config key="fov_y" value="45"/>
|
||||||
|
<config key="gamma" value="0"/>
|
||||||
|
<config key="nchannel" value="3"/>
|
||||||
|
</plugin>
|
||||||
|
</sensor>
|
||||||
|
</mujoco>
|
||||||
@@ -0,0 +1,42 @@
|
|||||||
|
# Copyright 2022 DeepMind Technologies Limited
|
||||||
|
#
|
||||||
|
# Licensed under the Apache License, Version 2.0 (the "License");
|
||||||
|
# you may not use this file except in compliance with the License.
|
||||||
|
# You may obtain a copy of the License at
|
||||||
|
#
|
||||||
|
# https://www.apache.org/licenses/LICENSE-2.0
|
||||||
|
#
|
||||||
|
# Unless required by applicable law or agreed to in writing, software
|
||||||
|
# distributed under the License is distributed on an "AS IS" BASIS,
|
||||||
|
# WITHOUT WARRANTIES OR CONDITIONS OF ANY KIND, either express or implied.
|
||||||
|
# See the License for the specific language governing permissions and
|
||||||
|
# limitations under the License.
|
||||||
|
|
||||||
|
set(MUJOCO_SENSOR_INCLUDE
|
||||||
|
${CMAKE_CURRENT_SOURCE_DIR}/../..
|
||||||
|
${CMAKE_CURRENT_SOURCE_DIR}/../../src
|
||||||
|
)
|
||||||
|
|
||||||
|
set(MUJOCO_SENSOR_SRCS
|
||||||
|
sensor.cc
|
||||||
|
touch_grid.h
|
||||||
|
touch_grid.cc
|
||||||
|
)
|
||||||
|
|
||||||
|
add_library(sensor SHARED)
|
||||||
|
target_sources(sensor PRIVATE ${MUJOCO_SENSOR_SRCS})
|
||||||
|
target_include_directories(sensor PRIVATE ${MUJOCO_SENSOR_INCLUDE})
|
||||||
|
target_link_libraries(sensor PRIVATE mujoco)
|
||||||
|
target_compile_options(
|
||||||
|
sensor
|
||||||
|
PRIVATE ${AVX_COMPILE_OPTIONS}
|
||||||
|
${MUJOCO_MACOS_COMPILE_OPTIONS}
|
||||||
|
${EXTRA_COMPILE_OPTIONS}
|
||||||
|
${MUJOCO_CXX_FLAGS}
|
||||||
|
)
|
||||||
|
target_link_options(
|
||||||
|
sensor
|
||||||
|
PRIVATE
|
||||||
|
${MUJOCO_MACOS_LINK_OPTIONS}
|
||||||
|
${EXTRA_LINK_OPTIONS}
|
||||||
|
)
|
||||||
@@ -0,0 +1,74 @@
|
|||||||
|
# Sensor Plugins
|
||||||
|
|
||||||
|
Custom sensors implemented as [engine plugins](https://mujoco.readthedocs.io/en/latest/programming/extension.html#engine-plugins).
|
||||||
|
|
||||||
|
## Touch Grid
|
||||||
|
|
||||||
|
This sensor aggregates contact forces into "taxels": a rectangular array of pixel-like elements.
|
||||||
|
|
||||||
|
|
||||||
|
A `touch grid` sensor is associated with a site and senses contact forces and
|
||||||
|
torques between the site's parent body and all other bodies. The site's frame
|
||||||
|
determines the orientation of the sensor with the same convention used for
|
||||||
|
cameras and lights: the sensor points in the frame's **negative-z** direction,
|
||||||
|
so the x and y axes correspond to horizontal and vertical, respectively.
|
||||||
|
|
||||||
|
The output of the sensor is a stack of 1 to 6 "touch images" corresponding to forces
|
||||||
|
and torques in the frame of the sensor. Forces and torques are in the in [z, x,
|
||||||
|
y] order, corresponding to the ordering in contact frames: [normal, tangent,
|
||||||
|
tangent] and [torsional, rolling, rolling]. Each "taxel" codderponds to an angular bin
|
||||||
|
in spherical coordinates, and aggregates all the forces occuring inside this bin, which occur
|
||||||
|
between the body in which the sensor's site is defined and any other body.
|
||||||
|
|
||||||
|
The sensor is parametrized by 6 numbers:
|
||||||
|
|
||||||
|
1. Number of channels, in the order given above. _positive integer in [1 6]_
|
||||||
|
2. Horizontal resolution. _positive integer_
|
||||||
|
3. Vertical resolution. _positive integer_
|
||||||
|
4. Horizontal field-of-view. _positive float in (0, 180] degrees_
|
||||||
|
5. Vertical field-of-view. _positive float in (0, 90] degrees_
|
||||||
|
6. Foveal deformation. _positive float in [0, 1]_
|
||||||
|
|
||||||
|
See illustrations below for a visual explanation of the field-of-view and foveal
|
||||||
|
deformation parameters. These parameters are passed as plugin config attributes:
|
||||||
|
|
||||||
|
```xml
|
||||||
|
<mujoco>
|
||||||
|
<extension>
|
||||||
|
<plugin plugin="mujoco.sensor.touch_grid"/>
|
||||||
|
</extension>
|
||||||
|
...
|
||||||
|
<sensor>
|
||||||
|
<plugin name="touch" plugin="mujoco.sensor.touch_grid" objtype="site" objname="touch">
|
||||||
|
<config key="nchannel" value="3"/>
|
||||||
|
<config key="size_x" value="7"/>
|
||||||
|
<config key="size_y" value="7"/>
|
||||||
|
<config key="fov_x" value="45"/>
|
||||||
|
<config key="fov_y" value="45"/>
|
||||||
|
<config key="gamma" value="0"/>
|
||||||
|
</plugin>
|
||||||
|
</sensor>
|
||||||
|
</mujoco>
|
||||||
|
```
|
||||||
|
|
||||||
|
Note the following:
|
||||||
|
|
||||||
|
- The dimensionality of the sensor output is `nchannel * size_x *size_y`.
|
||||||
|
- `objtype="site" objname="touch"` specify that the sensor is associated with
|
||||||
|
a site, and the name of the specific site.
|
||||||
|
- Field-of-view angles are always in degrees, disregarding the `<compiler>`
|
||||||
|
"angle" directive.
|
||||||
|
|
||||||
|
### Illustration of fields-of-view in spherical coordinates:
|
||||||
|
|
||||||
|
<img src="images/30-30.png" style="width: 300px;"/>
|
||||||
|
<img src="images/180-30.png" style="width: 300px;"/>
|
||||||
|
<img src="images/180-90.png" style="width: 300px;"/>
|
||||||
|
|
||||||
|
### Illustration of foveal deformation:
|
||||||
|
|
||||||
|

|
||||||
|
|
||||||
|
### Illustration combining resolution, fields-of-view and foveal deformation:
|
||||||
|
|
||||||
|
[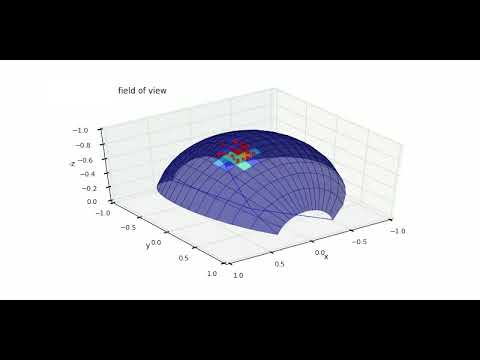](https://www.youtube.com/watch?v=YScjmR8LwQI)
|
||||||

Binary file not shown.
|
After Width: | Height: | Size: 108 KiB |

Binary file not shown.
|
After Width: | Height: | Size: 122 KiB |

Binary file not shown.
|
After Width: | Height: | Size: 62 KiB |

Binary file not shown.
|
After Width: | Height: | Size: 8.9 KiB |
@@ -0,0 +1,22 @@
|
|||||||
|
// Copyright 2023 DeepMind Technologies Limited
|
||||||
|
//
|
||||||
|
// Licensed under the Apache License, Version 2.0 (the "License");
|
||||||
|
// you may not use this file except in compliance with the License.
|
||||||
|
// You may obtain a copy of the License at
|
||||||
|
//
|
||||||
|
// http://www.apache.org/licenses/LICENSE-2.0
|
||||||
|
//
|
||||||
|
// Unless required by applicable law or agreed to in writing, software
|
||||||
|
// distributed under the License is distributed on an "AS IS" BASIS,
|
||||||
|
// WITHOUT WARRANTIES OR CONDITIONS OF ANY KIND, either express or implied.
|
||||||
|
// See the License for the specific language governing permissions and
|
||||||
|
// limitations under the License.
|
||||||
|
|
||||||
|
#include <mujoco/mjplugin.h>
|
||||||
|
#include "touch_grid.h"
|
||||||
|
|
||||||
|
namespace mujoco::plugin::sensor {
|
||||||
|
|
||||||
|
mjPLUGIN_LIB_INIT { TouchGrid::RegisterPlugin(); }
|
||||||
|
|
||||||
|
} // namespace mujoco::plugin::sensor
|
||||||
@@ -0,0 +1,535 @@
|
|||||||
|
// Copyright 2023 DeepMind Technologies Limited
|
||||||
|
//
|
||||||
|
// Licensed under the Apache License, Version 2.0 (the "License");
|
||||||
|
// you may not use this file except in compliance with the License.
|
||||||
|
// You may obtain a copy of the License at
|
||||||
|
//
|
||||||
|
// http://www.apache.org/licenses/LICENSE-2.0
|
||||||
|
//
|
||||||
|
// Unless required by applicable law or agreed to in writing, software
|
||||||
|
// distributed under the License is distributed on an "AS IS" BASIS,
|
||||||
|
// WITHOUT WARRANTIES OR CONDITIONS OF ANY KIND, either express or implied.
|
||||||
|
// See the License for the specific language governing permissions and
|
||||||
|
// limitations under the License.
|
||||||
|
|
||||||
|
#include "touch_grid.h"
|
||||||
|
|
||||||
|
#include <algorithm>
|
||||||
|
#include <cctype>
|
||||||
|
#include <cstdint>
|
||||||
|
#include <cstdlib>
|
||||||
|
#include <optional>
|
||||||
|
#include <string>
|
||||||
|
#include <utility>
|
||||||
|
|
||||||
|
#include <mujoco/mjdata.h>
|
||||||
|
#include <mujoco/mjmodel.h>
|
||||||
|
#include <mujoco/mjplugin.h>
|
||||||
|
#include <mujoco/mjtnum.h>
|
||||||
|
#include <mujoco/mjvisualize.h>
|
||||||
|
#include <mujoco/mujoco.h>
|
||||||
|
|
||||||
|
namespace mujoco::plugin::sensor {
|
||||||
|
|
||||||
|
namespace {
|
||||||
|
|
||||||
|
// Returns the index of the first value in `a` that x is less than or n if no
|
||||||
|
// such value exists. See: https://stackoverflow.com/a/39100135.
|
||||||
|
int LowerBound(const mjtNum a[], int n, mjtNum x) {
|
||||||
|
int l = 0;
|
||||||
|
int h = n;
|
||||||
|
while (l < h) {
|
||||||
|
int mid = (l + h) / 2;
|
||||||
|
if (x <= a[mid]) {
|
||||||
|
h = mid;
|
||||||
|
} else {
|
||||||
|
l = mid + 1;
|
||||||
|
}
|
||||||
|
}
|
||||||
|
return l;
|
||||||
|
}
|
||||||
|
|
||||||
|
// Two dimensional histogram function.
|
||||||
|
void Histogram2D(const mjtNum x_data[], const mjtNum y_data[],
|
||||||
|
const mjtNum weights[], int n_data, const mjtNum x_edges[],
|
||||||
|
int n_x_edges, const mjtNum y_edges[], int n_y_edges,
|
||||||
|
mjtNum* histogram, int* counts) {
|
||||||
|
for (int i = 0; i < n_data; ++i) {
|
||||||
|
mjtNum x = x_data[i];
|
||||||
|
mjtNum y = y_data[i];
|
||||||
|
int x_idx = LowerBound(x_edges, n_x_edges, x);
|
||||||
|
if (x_idx == 0 || x_idx == n_x_edges) {
|
||||||
|
continue;
|
||||||
|
}
|
||||||
|
int y_idx = LowerBound(y_edges, n_y_edges, y);
|
||||||
|
if (y_idx == 0 || y_idx == n_y_edges) {
|
||||||
|
continue;
|
||||||
|
}
|
||||||
|
int index = (y_idx - 1)*(n_x_edges - 1) + (x_idx - 1);
|
||||||
|
histogram[index] += weights[i];
|
||||||
|
if (counts) {
|
||||||
|
counts[index]++;
|
||||||
|
}
|
||||||
|
}
|
||||||
|
}
|
||||||
|
|
||||||
|
// Evenly spaced numbers over a specified interval.
|
||||||
|
void LinSpace(mjtNum lower, mjtNum upper, int n, mjtNum array[]) {
|
||||||
|
mjtNum increment = n > 1 ? (upper - lower) / (n - 1) : 0;
|
||||||
|
for (int i = 0; i < n; ++i) {
|
||||||
|
*array = lower;
|
||||||
|
++array;
|
||||||
|
lower += increment;
|
||||||
|
}
|
||||||
|
}
|
||||||
|
|
||||||
|
// Parametrized linear/quintic interpolated nonlinearity.
|
||||||
|
mjtNum Fovea(mjtNum x, mjtNum gamma) {
|
||||||
|
// Quick return.
|
||||||
|
if (!gamma) return x;
|
||||||
|
|
||||||
|
// Foveal deformation.
|
||||||
|
mjtNum g = mjMAX(0, mjMIN(1, gamma));
|
||||||
|
return g*mju_pow(x, 5) + (1 - g)*x;
|
||||||
|
}
|
||||||
|
|
||||||
|
// Make bin edges.
|
||||||
|
void BinEdges(mjtNum* x_edges, mjtNum* y_edges, int size_x, int size_y,
|
||||||
|
mjtNum fov_x, mjtNum fov_y, mjtNum gamma) {
|
||||||
|
// Make unit bin edges.
|
||||||
|
LinSpace(-1, 1, size_x + 1, x_edges);
|
||||||
|
LinSpace(-1, 1, size_y + 1, y_edges);
|
||||||
|
|
||||||
|
// Apply foveal deformation.
|
||||||
|
for (int i = 0; i < size_x + 1; i++) {
|
||||||
|
x_edges[i] = Fovea(x_edges[i], gamma);
|
||||||
|
}
|
||||||
|
for (int i = 0; i < size_y + 1; i++) {
|
||||||
|
y_edges[i] = Fovea(y_edges[i], gamma);
|
||||||
|
}
|
||||||
|
|
||||||
|
// Scale by field-of-view.
|
||||||
|
mju_scl(x_edges, x_edges, fov_x*mjPI / 180, size_x + 1);
|
||||||
|
mju_scl(y_edges, y_edges, fov_y*mjPI / 180, size_y + 1);
|
||||||
|
}
|
||||||
|
|
||||||
|
// Permute 3-vector from 0,1,2 to 2,0,1.
|
||||||
|
static void xyz2zxy(mjtNum* x) {
|
||||||
|
mjtNum z = x[2];
|
||||||
|
x[2] = x[1];
|
||||||
|
x[1] = x[0];
|
||||||
|
x[0] = z;
|
||||||
|
}
|
||||||
|
|
||||||
|
// In the functions below transforming Cartesian <-> spherical:
|
||||||
|
// - The frame points down the z-axis, so a=e=0 corresponds to (0, 0, -r).
|
||||||
|
// - azimuth (a) corresponds to positive rotation around -y (towards +x).
|
||||||
|
// - elevation (e) corresponds to positive rotation around +x (towards +y).
|
||||||
|
|
||||||
|
// Transform Cartesian (x,y,z) to spherical (azimuth, elevation, radius).
|
||||||
|
void CartesianToSpherical(const mjtNum xyz[3], mjtNum aer[3]) {
|
||||||
|
mjtNum x = xyz[0], y = xyz[1], z = xyz[2];
|
||||||
|
aer[0] = mju_atan2(x, -z);
|
||||||
|
aer[1] = mju_atan2(y, mju_sqrt(x*x + z*z));
|
||||||
|
aer[2] = mju_sqrt(x*x + z*z + y*y);
|
||||||
|
}
|
||||||
|
|
||||||
|
// Transform spherical (azimuth, elevation, radius) to Cartesian (x,y,z).
|
||||||
|
void SphericalToCartesian(const mjtNum aer[3], mjtNum xyz[3]) {
|
||||||
|
mjtNum a = aer[0], e = aer[1], r = aer[2];
|
||||||
|
xyz[0] = r * mju_cos(e) * mju_sin(a);
|
||||||
|
xyz[1] = r * mju_sin(e);
|
||||||
|
xyz[2] = -r * mju_cos(e) * mju_cos(a);
|
||||||
|
}
|
||||||
|
|
||||||
|
// Checks that a plugin config attribute exists.
|
||||||
|
bool CheckAttr(const char* name, const mjModel* m, int instance) {
|
||||||
|
char* end;
|
||||||
|
std::string value = mj_getPluginConfig(m, instance, name);
|
||||||
|
value.erase(std::remove_if(value.begin(), value.end(), isspace), value.end());
|
||||||
|
strtod(value.c_str(), &end);
|
||||||
|
return end == value.data() + value.size();
|
||||||
|
}
|
||||||
|
|
||||||
|
} // namespace
|
||||||
|
|
||||||
|
// Creates a TouchGrid instance if all config attributes are defined and
|
||||||
|
// within their allowed bounds.
|
||||||
|
TouchGrid* TouchGrid::Create(const mjModel* m, mjData* d,
|
||||||
|
int instance) {
|
||||||
|
if (CheckAttr("size_x", m, instance) && CheckAttr("size_y", m, instance) &&
|
||||||
|
CheckAttr("fov_x", m, instance) && CheckAttr("fov_y", m, instance) &&
|
||||||
|
CheckAttr("gamma", m, instance)) {
|
||||||
|
// nchannel
|
||||||
|
int nchannel = strtod(mj_getPluginConfig(m, instance, "nchannel"), nullptr);
|
||||||
|
if (!nchannel) nchannel = 1;
|
||||||
|
if (nchannel < 1 || nchannel > 6) {
|
||||||
|
mju_warning("nchannel must be between 1 and 6");
|
||||||
|
return nullptr;
|
||||||
|
}
|
||||||
|
|
||||||
|
// size_x, size_y
|
||||||
|
int size_x = strtod(mj_getPluginConfig(m, instance, "size_x"), nullptr);
|
||||||
|
int size_y = strtod(mj_getPluginConfig(m, instance, "size_y"), nullptr);
|
||||||
|
if (size_x < 0 || size_y < 0) {
|
||||||
|
mju_warning("Horizontal and vertical resolutions must be positive");
|
||||||
|
return nullptr;
|
||||||
|
}
|
||||||
|
|
||||||
|
// fov_x, fov_y
|
||||||
|
mjtNum fov_x = strtod(mj_getPluginConfig(m, instance, "fov_x"), nullptr);
|
||||||
|
if (fov_x <= 0 || fov_x > 180) {
|
||||||
|
mju_warning("`fov_x` must be a float between (0, 180] degrees");
|
||||||
|
return nullptr;
|
||||||
|
}
|
||||||
|
mjtNum fov_y = strtod(mj_getPluginConfig(m, instance, "fov_y"), nullptr);
|
||||||
|
if (fov_y <= 0 || fov_y > 90) {
|
||||||
|
mju_warning("`fov_y` must be a float between (0, 90] degrees");
|
||||||
|
return nullptr;
|
||||||
|
}
|
||||||
|
|
||||||
|
// gamma
|
||||||
|
mjtNum gamma = strtod(mj_getPluginConfig(m, instance, "gamma"), nullptr);
|
||||||
|
if (gamma < 0 || gamma > 1) {
|
||||||
|
mju_warning("`gamma` must be a nonnegative float between [0, 1]");
|
||||||
|
return nullptr;
|
||||||
|
}
|
||||||
|
|
||||||
|
return new TouchGrid(m, d, instance, nchannel, size_x, size_y,
|
||||||
|
fov_x, fov_y, gamma);
|
||||||
|
} else {
|
||||||
|
mju_warning("Invalid or missing parameters in touch_grid sensor plugin");
|
||||||
|
return nullptr;
|
||||||
|
}
|
||||||
|
}
|
||||||
|
|
||||||
|
TouchGrid::TouchGrid(const mjModel* m, mjData* d, int instance,
|
||||||
|
int nchannel, int size_x, int size_y, mjtNum fov_x,
|
||||||
|
mjtNum fov_y, mjtNum gamma)
|
||||||
|
: nchannel_(nchannel),
|
||||||
|
size_x_(size_x),
|
||||||
|
size_y_(size_y),
|
||||||
|
fov_x_(fov_x),
|
||||||
|
fov_y_(fov_y),
|
||||||
|
gamma_(gamma) {
|
||||||
|
// Make sure sensor is attached to a site.
|
||||||
|
for (int i = 0; i < m->nsensor; ++i) {
|
||||||
|
if (m->sensor_type[i] == mjSENS_PLUGIN && m->sensor_plugin[i] == instance) {
|
||||||
|
if (m->sensor_objtype[i] != mjOBJ_SITE) {
|
||||||
|
mju_error("Touch Grid sensor must be attached to a site");
|
||||||
|
}
|
||||||
|
}
|
||||||
|
}
|
||||||
|
|
||||||
|
// Allocate distance array.
|
||||||
|
distance_.resize(size_x*size_y, 0);
|
||||||
|
}
|
||||||
|
|
||||||
|
void TouchGrid::Reset(const mjModel* m, int instance) {}
|
||||||
|
|
||||||
|
void TouchGrid::Compute(const mjModel* m, mjData* d, int instance) {
|
||||||
|
mjMARKSTACK;
|
||||||
|
|
||||||
|
// Get sensor id.
|
||||||
|
int id;
|
||||||
|
for (id = 0; id < m->nsensor; ++id) {
|
||||||
|
if (m->sensor_type[id] == mjSENS_PLUGIN &&
|
||||||
|
m->sensor_plugin[id] == instance) {
|
||||||
|
break;
|
||||||
|
}
|
||||||
|
}
|
||||||
|
|
||||||
|
// Clear sensordata and distance matrix.
|
||||||
|
mjtNum* sensordata = d->sensordata + m->sensor_adr[id];
|
||||||
|
mju_zero(sensordata, m->sensor_dim[id]);
|
||||||
|
int frame = size_x_*size_y_;
|
||||||
|
mju_zero(distance_.data(), frame);
|
||||||
|
|
||||||
|
// Get site id.
|
||||||
|
int site_id = m->sensor_objid[id];
|
||||||
|
|
||||||
|
// Count contacts.
|
||||||
|
int ncon = 0;
|
||||||
|
int parent_body = m->body_weldid[m->site_bodyid[site_id]];
|
||||||
|
int parent_weld = m->body_weldid[parent_body];
|
||||||
|
for (int i = 0; i < d->ncon; i++) {
|
||||||
|
int body1 = m->body_weldid[m->geom_bodyid[d->contact[i].geom1]];
|
||||||
|
int body2 = m->body_weldid[m->geom_bodyid[d->contact[i].geom2]];
|
||||||
|
if (body1 == parent_weld || body2 == parent_weld) {
|
||||||
|
ncon++;
|
||||||
|
}
|
||||||
|
}
|
||||||
|
|
||||||
|
// No contacts, return.
|
||||||
|
if (!ncon) {
|
||||||
|
mjFREESTACK;
|
||||||
|
return;
|
||||||
|
}
|
||||||
|
|
||||||
|
// Get site frame.
|
||||||
|
mjtNum* site_pos = d->site_xpos + 3*site_id;
|
||||||
|
mjtNum* site_mat = d->site_xmat + 9*site_id;
|
||||||
|
|
||||||
|
// allocate contact forces and positions
|
||||||
|
mjtNum* forces = mj_stackAlloc(d, ncon*6);
|
||||||
|
mjtNum* positions = mj_stackAlloc(d, ncon*3);
|
||||||
|
|
||||||
|
// Get forces and positions in spherical coordinates.
|
||||||
|
int contact = 0;
|
||||||
|
for (int i = 0; i < d->ncon; i++) {
|
||||||
|
int body1 = m->geom_bodyid[d->contact[i].geom1];
|
||||||
|
int weld1 = m->body_weldid[body1];
|
||||||
|
int body2 = m->geom_bodyid[d->contact[i].geom2];
|
||||||
|
int weld2 = m->body_weldid[body2];
|
||||||
|
|
||||||
|
if (weld1 == parent_weld || weld2 == parent_weld) {
|
||||||
|
// Get contact force/torque, rotate into world frame, then site frame.
|
||||||
|
// Note that contact.frame is column major.
|
||||||
|
mjtNum tmp_force[6], tmp1[3];
|
||||||
|
mj_contactForce(m, d, i, tmp_force);
|
||||||
|
mju_rotVecMatT(tmp1, tmp_force, d->contact[i].frame);
|
||||||
|
mju_rotVecMatT(forces + 6*contact, tmp1, site_mat);
|
||||||
|
mju_rotVecMatT(tmp1, tmp_force + 3, d->contact[i].frame);
|
||||||
|
mju_rotVecMatT(forces + 6*contact + 3, tmp1, site_mat);
|
||||||
|
|
||||||
|
// Forces point from the smaller to larger body, so flip sign if
|
||||||
|
// the parent body has smaller id.
|
||||||
|
if (parent_body < mjMAX(body1, body2)) {
|
||||||
|
mju_scl(forces + 6*contact, forces + 6*contact, -1, 6);
|
||||||
|
}
|
||||||
|
|
||||||
|
// Permute forces from x,y,z to z,x,y (normal, tangent, tangent)
|
||||||
|
xyz2zxy(forces + 6*contact);
|
||||||
|
xyz2zxy(forces + 6*contact + 3);
|
||||||
|
|
||||||
|
// Get position, rotate into contact frame.
|
||||||
|
mjtNum tmp2[3];
|
||||||
|
mju_sub3(tmp1, d->contact[i].pos, site_pos);
|
||||||
|
mju_rotVecMatT(tmp2, tmp1, site_mat);
|
||||||
|
|
||||||
|
// Transform to spherical coordinates, copy into positions array.
|
||||||
|
CartesianToSpherical(tmp2, tmp1);
|
||||||
|
for (int k = 0; k < 3; k++) {
|
||||||
|
positions[k*ncon + contact] = tmp1[k];
|
||||||
|
}
|
||||||
|
contact++;
|
||||||
|
}
|
||||||
|
}
|
||||||
|
|
||||||
|
// Transpose forces.
|
||||||
|
mjtNum* forcesT = mj_stackAlloc(d, ncon*6);
|
||||||
|
mju_transpose(forcesT, forces, ncon, 6);
|
||||||
|
|
||||||
|
// Allocate bin edges.
|
||||||
|
mjtNum* x_edges = mj_stackAlloc(d, size_x_ + 1);
|
||||||
|
mjtNum* y_edges = mj_stackAlloc(d, size_y_ + 1);
|
||||||
|
|
||||||
|
// Make bin edges.
|
||||||
|
BinEdges(x_edges, y_edges, size_x_, size_y_, fov_x_, fov_y_, gamma_);
|
||||||
|
|
||||||
|
// Compute sensor output.
|
||||||
|
for (int i = 0; i < nchannel_; i++) {
|
||||||
|
if (!mju_isZero(forcesT + i*ncon, ncon)) {
|
||||||
|
Histogram2D(positions, positions + ncon, forcesT + i*ncon, ncon,
|
||||||
|
x_edges, size_x_ + 1, y_edges, size_y_ + 1,
|
||||||
|
sensordata + i*frame, nullptr);
|
||||||
|
}
|
||||||
|
}
|
||||||
|
|
||||||
|
// Allocate count matrix.
|
||||||
|
int* counts = mj_stackAllocInt(d, frame);
|
||||||
|
for (int i=0; i < frame; i++) counts[i] = 0;
|
||||||
|
|
||||||
|
// Compute distance matrix (unnormalized).
|
||||||
|
Histogram2D(positions, positions + ncon, positions + 2*ncon, ncon, x_edges,
|
||||||
|
size_x_ + 1, y_edges, size_y_ + 1, distance_.data(), counts);
|
||||||
|
|
||||||
|
// Normalize distances
|
||||||
|
for (int i=0; i < frame; i++) {
|
||||||
|
if (counts[i]) {
|
||||||
|
distance_.data()[i] /= counts[i];
|
||||||
|
}
|
||||||
|
}
|
||||||
|
|
||||||
|
mjFREESTACK;
|
||||||
|
}
|
||||||
|
|
||||||
|
// Thickness of taxel-visualization boxes relative to contact distance.
|
||||||
|
static const mjtNum kRelativeThickness = 0.02;
|
||||||
|
|
||||||
|
void TouchGrid::Visualize(const mjModel* m, mjData* d, const mjvOption* opt,
|
||||||
|
mjvScene* scn, int instance) {
|
||||||
|
mjMARKSTACK;
|
||||||
|
|
||||||
|
// Get sensor id.
|
||||||
|
int id;
|
||||||
|
for (id=0; id < m->nsensor; ++id) {
|
||||||
|
if (m->sensor_type[id] == mjSENS_PLUGIN &&
|
||||||
|
m->sensor_plugin[id] == instance) {
|
||||||
|
break;
|
||||||
|
}
|
||||||
|
}
|
||||||
|
|
||||||
|
// Get sensor data.
|
||||||
|
mjtNum* sensordata = d->sensordata + m->sensor_adr[id];
|
||||||
|
|
||||||
|
// Get maximum absolute normal force.
|
||||||
|
mjtNum maxval = 0;
|
||||||
|
int frame = size_x_*size_y_;
|
||||||
|
for (int j=0; j < frame; j++) {
|
||||||
|
maxval = mju_max(maxval, mju_abs(sensordata[j]));
|
||||||
|
}
|
||||||
|
|
||||||
|
// If no normal force readings, quick return.
|
||||||
|
if (!maxval) {
|
||||||
|
mjFREESTACK;
|
||||||
|
return;
|
||||||
|
}
|
||||||
|
|
||||||
|
// Get site id and frame.
|
||||||
|
int site_id = m->sensor_objid[id];
|
||||||
|
mjtNum* site_pos = d->site_xpos + 3*site_id;
|
||||||
|
mjtNum* site_mat = d->site_xmat + 9*site_id;
|
||||||
|
mjtNum site_quat[4];
|
||||||
|
mju_mat2Quat(site_quat, site_mat);
|
||||||
|
|
||||||
|
// Allocate bin edges.
|
||||||
|
mjtNum* x_edges = mj_stackAlloc(d, size_x_ + 1);
|
||||||
|
mjtNum* y_edges = mj_stackAlloc(d, size_y_ + 1);
|
||||||
|
|
||||||
|
// Make bin edges.
|
||||||
|
BinEdges(x_edges, y_edges, size_x_, size_y_, fov_x_, fov_y_, gamma_);
|
||||||
|
|
||||||
|
// Draw geoms.
|
||||||
|
for (int i=0; i < size_x_; i++) {
|
||||||
|
for (int j=0; j < size_y_; j++) {
|
||||||
|
mjtNum dist = distance_.data()[j*size_x_ + i];
|
||||||
|
if (!dist) {
|
||||||
|
continue;
|
||||||
|
}
|
||||||
|
if (scn->ngeom >= scn->maxgeom) {
|
||||||
|
mj_warning(d, mjWARN_VGEOMFULL, scn->maxgeom);
|
||||||
|
mjFREESTACK;
|
||||||
|
return;
|
||||||
|
} else {
|
||||||
|
// size
|
||||||
|
mjtNum size[3] = {dist*0.5*(x_edges[i+1]-x_edges[i]),
|
||||||
|
dist*0.5*(y_edges[j+1]-y_edges[j]),
|
||||||
|
dist*kRelativeThickness};
|
||||||
|
|
||||||
|
// position
|
||||||
|
mjtNum pos[3];
|
||||||
|
mjtNum aer[3] = {0.5*(x_edges[i+1]+x_edges[i]),
|
||||||
|
0.5*(y_edges[j+1]+y_edges[j]),
|
||||||
|
dist*(1-kRelativeThickness)};
|
||||||
|
SphericalToCartesian(aer, pos);
|
||||||
|
mju_rotVecMat(pos, pos, site_mat);
|
||||||
|
mju_addTo3(pos, site_pos);
|
||||||
|
|
||||||
|
// orientation
|
||||||
|
mjtNum a_quat[4];
|
||||||
|
mjtNum site_y[3] = {-site_mat[1], -site_mat[4], -site_mat[7]};
|
||||||
|
mju_axisAngle2Quat(a_quat, site_y, aer[0]);
|
||||||
|
mjtNum e_quat[4];
|
||||||
|
mjtNum site_x[3] = {site_mat[0], site_mat[3], site_mat[6]};
|
||||||
|
mju_axisAngle2Quat(e_quat, site_x, aer[1]);
|
||||||
|
mjtNum quat[4];
|
||||||
|
mju_mulQuat(quat, e_quat, site_quat);
|
||||||
|
mju_mulQuat(quat, a_quat, quat);
|
||||||
|
mjtNum mat[9];
|
||||||
|
mju_quat2Mat(mat, quat);
|
||||||
|
|
||||||
|
// color
|
||||||
|
float rgba[4] = {1, 1, 1, 1.0};
|
||||||
|
for (int k=0; k < mjMIN(nchannel_, 3); k++) {
|
||||||
|
rgba[k] = mju_abs(sensordata[k*frame + j*size_x_ + i]) / maxval;
|
||||||
|
}
|
||||||
|
|
||||||
|
// draw box geom
|
||||||
|
mjvGeom* thisgeom = scn->geoms + scn->ngeom;
|
||||||
|
mjv_initGeom(thisgeom, mjGEOM_BOX, size, pos, mat, rgba);
|
||||||
|
thisgeom->objtype = mjOBJ_UNKNOWN;
|
||||||
|
thisgeom->objid = id;
|
||||||
|
thisgeom->category = mjCAT_DECOR;
|
||||||
|
thisgeom->segid = scn->ngeom;
|
||||||
|
scn->ngeom++;
|
||||||
|
}
|
||||||
|
}
|
||||||
|
}
|
||||||
|
|
||||||
|
mjFREESTACK;
|
||||||
|
}
|
||||||
|
|
||||||
|
|
||||||
|
void TouchGrid::RegisterPlugin() {
|
||||||
|
mjpPlugin plugin;
|
||||||
|
mjp_defaultPlugin(&plugin);
|
||||||
|
|
||||||
|
plugin.name = "mujoco.sensor.touch_grid";
|
||||||
|
plugin.capabilityflags |= mjPLUGIN_SENSOR;
|
||||||
|
|
||||||
|
// Parameterized by 5 attributes.
|
||||||
|
const char* attributes[] = {"nchannel", "size_x", "size_y", "fov_x", "fov_y",
|
||||||
|
"gamma"};
|
||||||
|
plugin.nattribute = sizeof(attributes) / sizeof(attributes[0]);
|
||||||
|
plugin.attributes = attributes;
|
||||||
|
|
||||||
|
// Stateless.
|
||||||
|
plugin.nstate = +[](const mjModel* m, int instance) { return 0; };
|
||||||
|
|
||||||
|
// Sensor dimension = nchannel * size_x * size_y
|
||||||
|
plugin.nsensordata = +[](const mjModel* m, int instance, int sensor_id) {
|
||||||
|
int nchannel = strtod(mj_getPluginConfig(m, instance, "nchannel"), nullptr);
|
||||||
|
if (!nchannel) nchannel = 1;
|
||||||
|
int size_x = strtod(mj_getPluginConfig(m, instance, "size_x"), nullptr);
|
||||||
|
int size_y = strtod(mj_getPluginConfig(m, instance, "size_y"), nullptr);
|
||||||
|
return nchannel * size_x * size_y;
|
||||||
|
};
|
||||||
|
|
||||||
|
// Can only run after forces have been computed.
|
||||||
|
plugin.needstage = mjSTAGE_ACC;
|
||||||
|
|
||||||
|
// Initialization callback.
|
||||||
|
plugin.init = +[](const mjModel* m, mjData* d, int instance) {
|
||||||
|
auto* TouchGrid = TouchGrid::Create(m, d, instance);
|
||||||
|
if (!TouchGrid) {
|
||||||
|
return -1;
|
||||||
|
}
|
||||||
|
d->plugin_data[instance] = reinterpret_cast<uintptr_t>(TouchGrid);
|
||||||
|
return 0;
|
||||||
|
};
|
||||||
|
|
||||||
|
// Destruction callback.
|
||||||
|
plugin.destroy = +[](mjData* d, int instance) {
|
||||||
|
delete reinterpret_cast<TouchGrid*>(d->plugin_data[instance]);
|
||||||
|
d->plugin_data[instance] = 0;
|
||||||
|
};
|
||||||
|
|
||||||
|
// Reset callback.
|
||||||
|
plugin.reset = +[](const mjModel* m, double* plugin_state, void* plugin_data,
|
||||||
|
int instance) {
|
||||||
|
auto* TouchGrid = reinterpret_cast<class TouchGrid*>(plugin_data);
|
||||||
|
TouchGrid->Reset(m, instance);
|
||||||
|
};
|
||||||
|
|
||||||
|
// Compute callback.
|
||||||
|
plugin.compute =
|
||||||
|
+[](const mjModel* m, mjData* d, int instance, int capability_bit) {
|
||||||
|
auto* TouchGrid =
|
||||||
|
reinterpret_cast<class TouchGrid*>(d->plugin_data[instance]);
|
||||||
|
TouchGrid->Compute(m, d, instance);
|
||||||
|
};
|
||||||
|
|
||||||
|
// Visualization callback.
|
||||||
|
plugin.visualize = +[](const mjModel* m, mjData* d, const mjvOption* opt,
|
||||||
|
mjvScene* scn, int instance) {
|
||||||
|
auto* TouchGrid =
|
||||||
|
reinterpret_cast<class TouchGrid*>(d->plugin_data[instance]);
|
||||||
|
TouchGrid->Visualize(m, d, opt, scn, instance);
|
||||||
|
};
|
||||||
|
|
||||||
|
// Register the plugin.
|
||||||
|
mjp_registerPlugin(&plugin);
|
||||||
|
}
|
||||||
|
|
||||||
|
} // namespace mujoco::plugin::sensor
|
||||||
@@ -0,0 +1,75 @@
|
|||||||
|
// Copyright 2023 DeepMind Technologies Limited
|
||||||
|
//
|
||||||
|
// Licensed under the Apache License, Version 2.0 (the "License");
|
||||||
|
// you may not use this file except in compliance with the License.
|
||||||
|
// You may obtain a copy of the License at
|
||||||
|
//
|
||||||
|
// http://www.apache.org/licenses/LICENSE-2.0
|
||||||
|
//
|
||||||
|
// Unless required by applicable law or agreed to in writing, software
|
||||||
|
// distributed under the License is distributed on an "AS IS" BASIS,
|
||||||
|
// WITHOUT WARRANTIES OR CONDITIONS OF ANY KIND, either express or implied.
|
||||||
|
// See the License for the specific language governing permissions and
|
||||||
|
// limitations under the License.
|
||||||
|
|
||||||
|
#ifndef MUJOCO_PLUGIN_SENSOR_TOUCH_GRID_H_
|
||||||
|
#define MUJOCO_PLUGIN_SENSOR_TOUCH_GRID_H_
|
||||||
|
|
||||||
|
#include <optional>
|
||||||
|
#include <vector>
|
||||||
|
|
||||||
|
#include <mujoco/mjdata.h>
|
||||||
|
#include <mujoco/mjmodel.h>
|
||||||
|
#include <mujoco/mjtnum.h>
|
||||||
|
#include <mujoco/mjvisualize.h>
|
||||||
|
|
||||||
|
namespace mujoco::plugin::sensor {
|
||||||
|
|
||||||
|
// A touch grid sensor is associated with a site and senses contact forces
|
||||||
|
// and torques between the site's parent body and all other bodies. The site's
|
||||||
|
// frame determines the orientation of the sensor with the same convention used
|
||||||
|
// for cameras and lights: the sensor points in the frame's negative-Z
|
||||||
|
// direction, so the X and Y axes correspond to horizontal and vertical
|
||||||
|
// directions respectively.
|
||||||
|
//
|
||||||
|
// The output of the sensor is a stack of 6 "touch images" corresponding to
|
||||||
|
// forces and torques in the frame of the sensor. Forces and torques are in the
|
||||||
|
// [z, x, y] order, corresponding to the ordering in contact frames:
|
||||||
|
// [normal, tangent, tangent] and [torsional, rolling, rolling].
|
||||||
|
//
|
||||||
|
// The sensor has 6 parameters:
|
||||||
|
// 1. (int) Number of channels [1-6]. Defaults to 1.
|
||||||
|
// 2. (int) Horizontal resolution.
|
||||||
|
// 3. (int) Vertical resolution.
|
||||||
|
// 4. (float) Horizontal field-of-view (fov_x), in degrees.
|
||||||
|
// 5. (float) Vertical field-of-view (fov_y), in degrees.
|
||||||
|
// 6. (float) Foveal deformation. Defaults to 0.
|
||||||
|
class TouchGrid {
|
||||||
|
public:
|
||||||
|
static TouchGrid* Create(const mjModel* m, mjData* d, int instance);
|
||||||
|
TouchGrid(TouchGrid&&) = default;
|
||||||
|
~TouchGrid() = default;
|
||||||
|
|
||||||
|
void Reset(const mjModel* m, int instance);
|
||||||
|
void Compute(const mjModel* m, mjData* d, int instance);
|
||||||
|
void Visualize(const mjModel* m, mjData* d, const mjvOption* opt,
|
||||||
|
mjvScene* scn, int instance);
|
||||||
|
|
||||||
|
static void RegisterPlugin();
|
||||||
|
|
||||||
|
int nchannel_; // number of channels (1-6)
|
||||||
|
int size_x_; // horizontal resolution
|
||||||
|
int size_y_; // vertical resolution
|
||||||
|
mjtNum fov_x_; // horizontal field of view, in degrees
|
||||||
|
mjtNum fov_y_; // vertical field of view, in degrees
|
||||||
|
mjtNum gamma_; // foveal deformation
|
||||||
|
|
||||||
|
private:
|
||||||
|
TouchGrid(const mjModel* m, mjData* d, int instance, int nchannel, int size_x,
|
||||||
|
int size_y, mjtNum fov_x, mjtNum fov_y, mjtNum gamma);
|
||||||
|
std::vector<mjtNum> distance_;
|
||||||
|
};
|
||||||
|
|
||||||
|
} // namespace mujoco::plugin::sensor
|
||||||
|
|
||||||
|
#endif // MUJOCO_PLUGIN_SENSOR_TOUCH_GRID_H_
|
||||||
@@ -0,0 +1,21 @@
|
|||||||
|
# Copyright 2022 DeepMind Technologies Limited
|
||||||
|
#
|
||||||
|
# Licensed under the Apache License, Version 2.0 (the "License");
|
||||||
|
# you may not use this file except in compliance with the License.
|
||||||
|
# You may obtain a copy of the License at
|
||||||
|
#
|
||||||
|
# https://www.apache.org/licenses/LICENSE-2.0
|
||||||
|
#
|
||||||
|
# Unless required by applicable law or agreed to in writing, software
|
||||||
|
# distributed under the License is distributed on an "AS IS" BASIS,
|
||||||
|
# WITHOUT WARRANTIES OR CONDITIONS OF ANY KIND, either express or implied.
|
||||||
|
# See the License for the specific language governing permissions and
|
||||||
|
# limitations under the License.
|
||||||
|
|
||||||
|
mujoco_test(
|
||||||
|
sensor_test
|
||||||
|
PROPERTIES
|
||||||
|
ENVIRONMENT
|
||||||
|
"MUJOCO_PLUGIN_DIR=$<TARGET_FILE_DIR:sensor>"
|
||||||
|
)
|
||||||
|
target_link_libraries(sensor_test fixture gmock)
|
||||||
@@ -0,0 +1,45 @@
|
|||||||
|
// Copyright 2023 DeepMind Technologies Limited
|
||||||
|
//
|
||||||
|
// Licensed under the Apache License, Version 2.0 (the "License");
|
||||||
|
// you may not use this file except in compliance with the License.
|
||||||
|
// You may obtain a copy of the License at
|
||||||
|
//
|
||||||
|
// http://www.apache.org/licenses/LICENSE-2.0
|
||||||
|
//
|
||||||
|
// Unless required by applicable law or agreed to in writing, software
|
||||||
|
// distributed under the License is distributed on an "AS IS" BASIS,
|
||||||
|
// WITHOUT WARRANTIES OR CONDITIONS OF ANY KIND, either express or implied.
|
||||||
|
// See the License for the specific language governing permissions and
|
||||||
|
// limitations under the License.
|
||||||
|
|
||||||
|
// Tests for sensor plugins.
|
||||||
|
|
||||||
|
#include <string>
|
||||||
|
#include <gmock/gmock.h>
|
||||||
|
#include <gtest/gtest.h>
|
||||||
|
#include <mujoco/mjmodel.h>
|
||||||
|
#include <mujoco/mujoco.h>
|
||||||
|
#include "test/fixture.h"
|
||||||
|
|
||||||
|
namespace mujoco {
|
||||||
|
namespace {
|
||||||
|
|
||||||
|
using SensorPluginTest = MujocoTest;
|
||||||
|
|
||||||
|
static const char* const kTOuchGridPath =
|
||||||
|
"plugin/sensor/testdata/touch_grid_test.xml";
|
||||||
|
|
||||||
|
TEST_F(SensorPluginTest, ValidAttributes) {
|
||||||
|
const std::string xml_path = GetTestDataFilePath(kTOuchGridPath);
|
||||||
|
char error[1024] = {0};
|
||||||
|
mjModel* model = mj_loadXML(xml_path.c_str(), nullptr, error, sizeof(error));
|
||||||
|
ASSERT_THAT(model, testing::NotNull()) << error;
|
||||||
|
int nchannel = 3;
|
||||||
|
int size_x = 6;
|
||||||
|
int size_y = 2;
|
||||||
|
EXPECT_THAT(model->sensor_dim[0], nchannel * size_x * size_y);
|
||||||
|
mj_deleteModel(model);
|
||||||
|
}
|
||||||
|
|
||||||
|
} // namespace
|
||||||
|
} // namespace mujoco
|
||||||
+52
@@ -0,0 +1,52 @@
|
|||||||
|
<mujoco model="touchtest">
|
||||||
|
<extension>
|
||||||
|
<plugin plugin="mujoco.sensor.touch_grid"/>
|
||||||
|
</extension>
|
||||||
|
|
||||||
|
<asset>
|
||||||
|
<texture name="grid" type="2d" builtin="checker" rgb1=".1 .2 .3" rgb2=".2 .3 .4" width="300" height="300" mark="edge" markrgb=".2 .3 .4"/>
|
||||||
|
<material name="grid" texture="grid" texrepeat="3 1" texuniform="true"/>
|
||||||
|
</asset>
|
||||||
|
|
||||||
|
<visual>
|
||||||
|
<headlight ambient=".7 .7 .7" diffuse=".2 .2 .2" specular="0.1 0.1 0.1"/>
|
||||||
|
<map znear="0.01"/>
|
||||||
|
</visual>
|
||||||
|
|
||||||
|
<default>
|
||||||
|
<geom friction="0.4"/>
|
||||||
|
</default>
|
||||||
|
|
||||||
|
<statistic center="0 0 1" extent="1" meansize=".1"/>
|
||||||
|
|
||||||
|
<option gravity="0 0 -10"/>
|
||||||
|
|
||||||
|
<worldbody>
|
||||||
|
<body name="dummy2">
|
||||||
|
<geom name="floor" pos="0 0 0" type="plane" size="1 1 .01" material="grid"/>
|
||||||
|
</body>
|
||||||
|
|
||||||
|
<body name="dummy1">
|
||||||
|
<site name="touch" pos="0 0 10" group="3"/>
|
||||||
|
</body>
|
||||||
|
|
||||||
|
<body name="box" pos="0 0 .1">
|
||||||
|
<freejoint/>
|
||||||
|
<geom type="box" size=".1 .1 .1" mass="0.1"/>
|
||||||
|
</body>
|
||||||
|
|
||||||
|
<light pos="0 0 5"/>
|
||||||
|
|
||||||
|
</worldbody>
|
||||||
|
|
||||||
|
<sensor>
|
||||||
|
<plugin name="touch" plugin="mujoco.sensor.touch_grid" objtype="site" objname="touch">
|
||||||
|
<config key="size_x" value="6"/>
|
||||||
|
<config key="size_y" value="2"/>
|
||||||
|
<config key="fov_x" value="5.71"/>
|
||||||
|
<config key="fov_y" value="5.71"/>
|
||||||
|
<config key="gamma" value="0"/>
|
||||||
|
<config key="nchannel" value="3"/>
|
||||||
|
</plugin>
|
||||||
|
</sensor>
|
||||||
|
</mujoco>
|
||||||
Reference in New Issue
Block a user