add chinese
build / setup (compute matrix) (push) Has been cancelled
build / ${{ matrix.label }} (push) Has been cancelled
build / macos-15-arm64-studio (push) Has been cancelled
build / ubuntu-24.04-clang-18-studio (push) Has been cancelled
build / ubuntu-24.04-gcc-14-studio (push) Has been cancelled
build / windows-2025-ninja-studio (push) Has been cancelled
build / ubuntu-24.04-clang-18-wasm (push) Has been cancelled
build / ubuntu-24.04-clang-18-mjx (push) Has been cancelled
This commit is contained in:

@@ -1,9 +1,8 @@
|
||||
# Active adhesion example
|
||||
# 主动吸附示例
|
||||
|
||||
This example model shows how to use adhesion actuators.
|
||||
本示例模型演示了如何使用吸附执行器(Adhesion Actuator)。
|
||||
|
||||
The video below is a screen capture of a user interacting with the model:
|
||||
下方视频展示了用户与该模型进行交互的录屏:
|
||||
|
||||
|
||||
[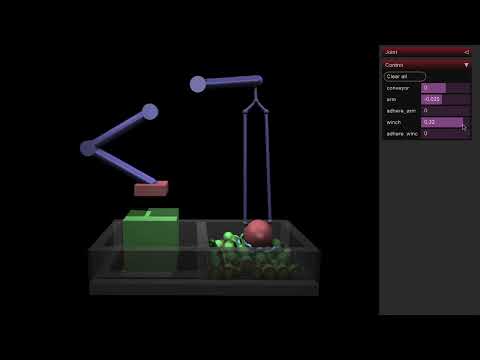](https://www.youtube.com/watch?v=BcHZ5BFeTmU)
|
||||
|
||||
[](https://www.youtube.com/watch?v=BcHZ5BFeTmU)
|
||||
|
||||
@@ -1,7 +1,7 @@
|
||||
# Cube
|
||||
# 魔方(Cube)
|
||||
|
||||
This model was contributed by Kevin Zakka. For details regarding its creation, see the associated [repository](https://github.com/kevinzakka/mujoco_cube).
|
||||
该模型由 Kevin Zakka 贡献。关于其创建的详细信息,请参阅相关[代码仓库](https://github.com/kevinzakka/mujoco_cube)。
|
||||
|
||||
Click the video below to see a user interacting with the cube:
|
||||
点击下方视频查看用户与魔方交互的演示:
|
||||
|
||||
[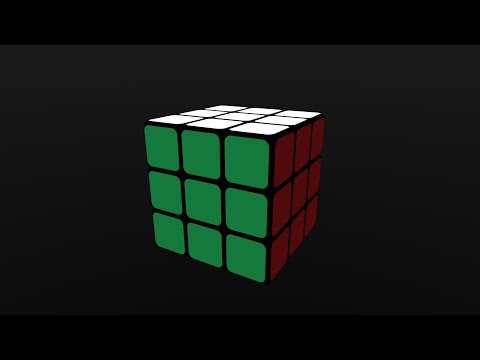](https://www.youtube.com/watch?v=ZppeDArq6AU)
|
||||
[](https://www.youtube.com/watch?v=ZppeDArq6AU)
|
||||
|
||||
+21
-23
@@ -1,35 +1,33 @@
|
||||
# Humanoid
|
||||
# 人形机器人(Humanoid)
|
||||
|
||||
This simplified humanoid model, introduced in [1], is designed for bipedal locomotion
|
||||
behaviours. While several variants of it exist in the wild, this version is based on the model
|
||||
in the DeepMind Control Suite [2], which has fairly realistic actuator gains.
|
||||
本简化人形机器人模型最初在文献 [1] 中提出,专为双足运动控制行为设计。尽管社区中存在多种变体,但此版本基于 DeepMind Control Suite [2] 中的模型构建,具备较为逼真的执行器增益。
|
||||
|
||||
* Degrees of Freedom: 27
|
||||
* Actuators: 21
|
||||
* 自由度(Degrees of Freedom):27
|
||||
* 执行器(Actuators):21
|
||||
|
||||
<p float="left">
|
||||
<img src="humanoid.png" width="400">
|
||||
</p>
|
||||
|
||||
## Changelog
|
||||
## 更新日志
|
||||
|
||||
* 08-10-2024: Moved tracking light from the torso to the world.
|
||||
* 20-02-2024: Sorted actuators in the same order as the joints.
|
||||
* 02-01-2024: Add more keyframes.
|
||||
* 27-11-2023: Move humanoid geoms to group 1.
|
||||
* 05-04-2023: Fix typo in texture size.
|
||||
* 20-09-2022: Use default class for left_upper_arm geom.
|
||||
* 17-09-2022: Increase offscreen render buffer resolution of the humanoid to 2560x1440.
|
||||
* 12-09-2022:
|
||||
* Increased maximum hip flexion.
|
||||
* Symmetrised shoulder and ankle joints.
|
||||
* Added hamstring tendons which couple the hip and knee at large flexion values.
|
||||
* Moved duplicated values into defaults.
|
||||
* Added two keyframes.
|
||||
* Improved lighting.
|
||||
* Changed naming convention.
|
||||
* 2024-10-08:将跟踪光源从躯干移动到全局世界(world)。
|
||||
* 2024-02-20:将执行器排序调整为与关节相同的顺序。
|
||||
* 2024-01-02:添加了更多关键帧。
|
||||
* 2023-11-27:将人形机器人的几何体移动到 group 1。
|
||||
* 2023-04-05:修复纹理尺寸中的拼写错误。
|
||||
* 2022-09-20:为 left_upper_arm geom 使用 default class。
|
||||
* 2022-09-17:将人形机器人的离屏渲染缓冲区分辨率提升至 2560x1440。
|
||||
* 2022-09-12:
|
||||
* 增大了髋关节最大屈曲角度。
|
||||
* 使肩关节和踝关节对称化。
|
||||
* 添加了腘绳肌肌腱(hamstring tendons),在大角度屈曲时耦合髋部和膝盖。
|
||||
* 将重复的属性值合并到 defaults。
|
||||
* 添加了两个关键帧。
|
||||
* 改进了光照效果。
|
||||
* 修改了命名规范。
|
||||
|
||||
## References
|
||||
## 参考文献
|
||||
|
||||
[1] [Synthesis and Stabilization of Complex Behaviors through Online Trajectory Optimization](https://doi.org/10.1109/IROS.2012.6386025).
|
||||
|
||||
|
||||
@@ -1,2 +1 @@
|
||||
The spot assets were taken from https://www.cs.cmu.edu/~kmcrane/Projects/ModelRepository/ and are
|
||||
released under the CC0 1.0 Universal (CC0 1.0) Public Domain Dedication license.
|
||||
Spot 相关的三维模型资产来源于 https://www.cs.cmu.edu/~kmcrane/Projects/ModelRepository/ ,并在 CC0 1.0 Universal (CC0 1.0) 公共领域贡献许可协议下发布。
|
||||
|
||||
@@ -1,27 +1,26 @@
|
||||
# Replicate
|
||||
# 复制元元素(Replicate)
|
||||
|
||||
Models in this directory provide usage examples of the `<replicate>` meta-element, see
|
||||
[documentation](https://mujoco.readthedocs.io/en/stable/XMLreference.html#replicate-r).
|
||||
此目录下的模型提供了 `<replicate>` 元元素的使用示例,详见[官方文档](https://mujoco.readthedocs.io/en/stable/XMLreference.html#replicate-r)。
|
||||
|
||||
The models contain several categories:
|
||||
这些模型涵盖以下几个类别:
|
||||
|
||||
1. Constructing static geometries:
|
||||
1. 构建静态几何体:
|
||||
- cylinder.xml
|
||||
- bowl.xml
|
||||
- helix.xml
|
||||
- container.xml
|
||||
|
||||
2. Replicating moving bodies:
|
||||
2. 复制运动刚体:
|
||||
- particle.xml
|
||||
- bunnies.xml
|
||||
- leaves.xml
|
||||
- stonehenge.xml
|
||||
|
||||
3. Replicas that include tendons:
|
||||
3. 包含肌腱/绳索(Tendon)的复制:
|
||||
- newton_cradle.xml
|
||||
- tendon.xml
|
||||
|
||||
4. Replicas with multiple referencing elements:
|
||||
4. 包含多个引用元素的复制:
|
||||
- references.xml
|
||||
|
||||
[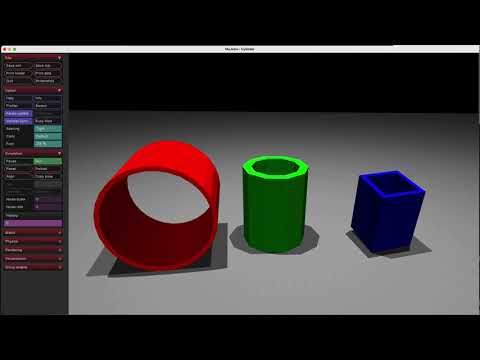](https://www.youtube.com/watch?v=5k0_wsIRAFc)
|
||||
[](https://www.youtube.com/watch?v=5k0_wsIRAFc)
|
||||
|
||||
Reference in New Issue
Block a user