add chinese
build / setup (compute matrix) (push) Has been cancelled
build / ${{ matrix.label }} (push) Has been cancelled
build / macos-15-arm64-studio (push) Has been cancelled
build / ubuntu-24.04-clang-18-studio (push) Has been cancelled
build / ubuntu-24.04-gcc-14-studio (push) Has been cancelled
build / windows-2025-ninja-studio (push) Has been cancelled
build / ubuntu-24.04-clang-18-wasm (push) Has been cancelled
build / ubuntu-24.04-clang-18-mjx (push) Has been cancelled
This commit is contained in:

+11
-11
@@ -1,13 +1,13 @@
|
||||
# Actuator plugins
|
||||
# 执行器插件(Actuator plugins)
|
||||
|
||||
## PID
|
||||
|
||||
The `mujoco.pid` actuator plugin implements a configurable [PID controller](https://en.wikipedia.org/wiki/Proportional%E2%80%93integral%E2%80%93derivative_controller):
|
||||
`mujoco.pid` 执行器插件实现了一个可配置的 [PID 控制器](https://en.wikipedia.org/wiki/Proportional%E2%80%93integral%E2%80%93derivative_controller):
|
||||
|
||||
$$f(t) = K_\text{p} e(t) + K_\text{i} \int_0^t e(\tau) \mathrm{d}\tau + K_\text{d} \frac{\mathrm{d}e(t)}{\mathrm{d}t},$$
|
||||
where $e(t) = u(t) - \ell(t)$ is the difference between the control $u$ and the actuator length $\ell$.
|
||||
其中 $e(t) = u(t) - \ell(t)$ 是控制量 $u$ 与执行器长度 $\ell$ 之间的差值。
|
||||
|
||||
You can use it like:
|
||||
使用示例如下:
|
||||
|
||||
```xml
|
||||
<mujoco>
|
||||
@@ -36,12 +36,12 @@ You can use it like:
|
||||
</mujoco>
|
||||
```
|
||||
|
||||
The available options are:
|
||||
可用配置选项如下:
|
||||
|
||||
|Attribute | Default | Meaning |
|
||||
|属性 | 默认值 | 含义 |
|
||||
|----------|---------|---------|
|
||||
|`kp` | 0 | **P** gain for the controller. |
|
||||
|`ki` | 0 | **I** gain for the controller.<p/>If nonzero, one activation variable will be added to `mjData.act`, containing the current I term (in units of force). |
|
||||
|`kd` | 0 | **D** gain for the controller. |
|
||||
|`imax` | Optional | If specified, the force produced by the I term will be clipped to the range `[-imax, imax]`. |
|
||||
|`slewmax` | Optional | The maximum rate at which the setpoint for the PID controller can change.<p/>If a bigger change is requested between two timesteps, it will be clipped to the range `[ctrl - slewmax * dt, ctrl + slewmax * dt]`<p/>If specified, one activation variable will be added to `mjData.act` containing the previous value of `ctrl`. |
|
||||
|`kp` | 0 | 控制器的**比例(P)**增益。 |
|
||||
|`ki` | 0 | 控制器的**积分(I)**增益。<p/>若非零,将在 `mjData.act` 中添加一个激活变量,用于存储当前的积分项(以力为单位)。 |
|
||||
|`kd` | 0 | 控制器的**微分(D)**增益。 |
|
||||
|`imax` | 可选 | 若指定,积分项产生的力将被截断至 `[-imax, imax]` 范围内。 |
|
||||
|`slewmax` | 可选 | PID 控制器设定点允许的最大变化速率(斜率限制)。<p/>若两个时间步之间请求了更大的变化,它将被截断至 `[ctrl - slewmax * dt, ctrl + slewmax * dt]` 范围。<p/>若指定,将在 `mjData.act` 中添加一个激活变量,用于存储上一个时间步的 `ctrl` 值。 |
|
||||
|
||||
+10
-10
@@ -2,19 +2,19 @@
|
||||
<a href="#"><img alt="MuJoCo" src="../../banner.png" width="100%"/></a>
|
||||
</h1>
|
||||
|
||||
## Elasticity plugins
|
||||
## 弹性插件(Elasticity plugins)
|
||||
|
||||
These are first-party plugins that implement passive forces based on discretized continuum mechanics models. They can be applied to **flexes** and **bodies** (via the **composite** functionality). Sample models can be found in [this folder](../../model/plugin/elasticity/).
|
||||
这些是第一方插件,基于离散连续介质力学模型实现被动力。它们可以应用于 **flexes**(柔性体)和 **bodies**(刚体,通过 **composite** 复合体功能)。示例模型可在[此文件夹](../../model/plugin/elasticity/)中找到。
|
||||
|
||||
### Cable
|
||||
### 缆绳(Cable)
|
||||
|
||||
Implemented in [cable.cc](cable.cc).
|
||||
在 [cable.cc](cable.cc) 中实现。
|
||||
|
||||
The cable plugin discretizes an inextensible 1D continuum. It is intended to simulate the twist and bending of rods where the stretching in negligible compared to the other deformation modes.
|
||||
缆绳插件离散化了一个不可伸长的一维连续介质。它旨在模拟细杆的扭转和弯曲,在这些场景下拉伸形变与其他形变模式相比可以忽略不计。
|
||||
|
||||
Parameters:
|
||||
参数:
|
||||
|
||||
- `twist` [Pa]: twisting stiffness.
|
||||
- `bend` [Pa]: bending stiffness.
|
||||
- `flat` [bool]: if true, the stress-equilibrium configuration is that of a straight cable; if false or unspecified, it is the configuration defined in the XML.
|
||||
- `vmax` [N/m^2]: If greater than zero, the cable is colored using mechanical stresses; the value represent the maximum stress in the color scale.
|
||||
- `twist` [Pa]:扭转刚度。
|
||||
- `bend` [Pa]:弯曲刚度。
|
||||
- `flat` [bool]:若为 true,应力平衡构型为直缆状态;若为 false 或未指定,则为 XML 中定义的初始构型。
|
||||
- `vmax` [N/m^2]:若大于零,缆绳将根据机械应力着色;该值代表颜色标尺中的最大应力。
|
||||
|
||||
+42
-51
@@ -2,106 +2,97 @@
|
||||
<a href="#"><img alt="MuJoCo" src="../../banner.png" width="100%"/></a>
|
||||
</h1>
|
||||
|
||||
## Signed distance function (SDF) plugins
|
||||
## 符号距离函数(SDF)插件
|
||||
|
||||
These are first-party plugins that implement implicit geometries using SDFs. They can be applied to **geoms** and
|
||||
**meshes** (in the **asset** section). Sample models can be found in [this folder](../../model/plugin/sdf/).
|
||||
这些是第一方插件,使用符号距离函数(Signed Distance Functions, SDF)实现隐式几何体。它们可以应用于 **geoms**(几何体)和 **meshes**(网格,在 **asset** 资产部分)。示例模型可在[此文件夹](../../model/plugin/sdf/)中找到。
|
||||
|
||||
### Bolt
|
||||
### 螺栓(Bolt)
|
||||
|
||||
Implemented in [bolt.cc](bolt.cc). Example usage in [nutbolt.xml](../../model/plugin/sdf/nutbolt.xml).
|
||||
在 [bolt.cc](bolt.cc) 中实现。使用示例见 [nutbolt.xml](../../model/plugin/sdf/nutbolt.xml)。
|
||||
|
||||
This plugin implements a bolt with a hexagonal head, similar to https://www.shadertoy.com/view/XtffzX.
|
||||
该插件实现了一个带有六角头的螺栓,类似于 https://www.shadertoy.com/view/XtffzX。
|
||||
|
||||
Parameters:
|
||||
参数:
|
||||
|
||||
- `radius` [m]: bolt radius (default `0.26`).
|
||||
- `radius` [m]:螺栓半径(默认 `0.26`)。
|
||||
|
||||
### Bowl
|
||||
### 碗(Bowl)
|
||||
|
||||
Implemented in [bowl.cc](bowl.cc). Example usage in [bowl.xml](../../model/plugin/sdf/bowl.xml).
|
||||
在 [bowl.cc](bowl.cc) 中实现。使用示例见 [bowl.xml](../../model/plugin/sdf/bowl.xml)。
|
||||
|
||||
The plugin implements a cut hollow sphere from https://www.shadertoy.com/view/7tVXRt.
|
||||
该插件实现了来自 https://www.shadertoy.com/view/7tVXRt 的被切割中空球体。
|
||||
|
||||
Parameters:
|
||||
参数:
|
||||
|
||||
- `height` [m]: location of the cut plane (default `0.4`).
|
||||
- `radius` [m]: radius of the sphere (default `1`).
|
||||
- `thickness` [m]: thickness of the bowl (default `0.02`).
|
||||
- `height` [m]:切割平面的位置(默认 `0.4`)。
|
||||
- `radius` [m]:球体半径(默认 `1`)。
|
||||
- `thickness` [m]:碗的壁厚(默认 `0.02`)。
|
||||
|
||||
### Gear
|
||||
### 齿轮(Gear)
|
||||
|
||||
Implemented in [gear.cc](gear.cc). Example usage in [gear.xml](../../model/plugin/sdf/gear.xml).
|
||||
在 [gear.cc](gear.cc) 中实现。使用示例见 [gear.xml](../../model/plugin/sdf/gear.xml)。
|
||||
|
||||
The plugin implements a 3D extrusion of the 2D gear geometry from https://www.shadertoy.com/view/3lG3WR.
|
||||
该插件实现了来自 https://www.shadertoy.com/view/3lG3WR 的 2D 齿轮几何体的 3D 拉伸挤出。
|
||||
|
||||
Parameters:
|
||||
参数:
|
||||
|
||||
- `alpha` [m]: initial angle of rotation of the gear (default `0`).
|
||||
- `diameter` [m]: gear diameter (default `2.8`).
|
||||
- `teeth` []: number of teeth (default `25`).
|
||||
- `alpha` [m]:齿轮的初始旋转角度(默认 `0`)。
|
||||
- `diameter` [m]:齿轮直径(默认 `2.8`)。
|
||||
- `teeth` []:齿数(默认 `25`)。
|
||||
|
||||
### Nut
|
||||
### 螺母(Nut)
|
||||
|
||||
Implemented in [nut.cc](nut.cc). Example usage in [nutbolt.xml](../../model/plugin/sdf/nutbolt.xml).
|
||||
在 [nut.cc](nut.cc) 中实现。使用示例见 [nutbolt.xml](../../model/plugin/sdf/nutbolt.xml)。
|
||||
|
||||
This plugin implements a hexagonal nut identical to the bolt head from https://www.shadertoy.com/view/XtffzX.
|
||||
该插件实现了一个六角螺母,与来自 https://www.shadertoy.com/view/XtffzX 的螺栓头部相同。
|
||||
|
||||
Parameters:
|
||||
参数:
|
||||
|
||||
- `radius` [m]: nut radius (default `0.26`).
|
||||
- `radius` [m]:螺母半径(默认 `0.26`)。
|
||||
|
||||
### Torus
|
||||
### 圆环体(Torus)
|
||||
|
||||
Implemented in [torus.cc](torus.cc). Example usage in [torus.xml](../../model/plugin/sdf/torus.xml).
|
||||
在 [torus.cc](torus.cc) 中实现。使用示例见 [torus.xml](../../model/plugin/sdf/torus.xml)。
|
||||
|
||||
This plugin implements a torus.
|
||||
该插件实现了一个圆环体。
|
||||
|
||||
Parameters:
|
||||
参数:
|
||||
|
||||
- `radius1` [m]: major radius (default `0.35`).
|
||||
- `radius1` [m]: minor radius (default `0.15`).
|
||||
- `radius1` [m]:主半径/大半径(默认 `0.35`)。
|
||||
- `radius1` [m]:次半径/小半径(默认 `0.15`)。
|
||||
|
||||
### How to make your own SDF
|
||||
### 如何创建自定义 SDF
|
||||
|
||||
Create your `MySDF.h` and `MySDF.cc` files in the SDF folder, where this README is located. Implement your SDF using the
|
||||
following interface:
|
||||
在当前 README 所在的 SDF 文件夹中创建您的 `MySDF.h` 和 `MySDF.cc` 文件。使用以下接口实现您的 SDF:
|
||||
|
||||
```
|
||||
```cpp
|
||||
struct MySDFAttribute {
|
||||
static constexpr int nattribute =
|
||||
/* insert the number of attributes */;
|
||||
/* 填入属性数量 */;
|
||||
static constexpr char const* names[nattribute] =
|
||||
/* an array of attributes with the same order as the attribute array in your SDF class */;
|
||||
/* 与 SDF 类中属性数组顺序相同的属性名称数组 */;
|
||||
static constexpr mjtNum defaults[nattribute] =
|
||||
/* an array of default values for your attributes */;
|
||||
/* 属性的默认值数组 */;
|
||||
};
|
||||
|
||||
class MySDF {
|
||||
public:
|
||||
// creates a new MySDF instance or returns null on failure.
|
||||
// 创建新的 MySDF 实例,失败时返回 null。
|
||||
static std::optional<MySDF> Create(const mjModel* m, mjData* d, int instance);
|
||||
MySDF(MySDF&&) = default;
|
||||
~MySDF() = default;
|
||||
|
||||
// functions that return the SDF and its gradient at a query point
|
||||
// 在查询点返回 SDF 距离及其梯度的函数
|
||||
mjtNum Distance(const mjtNum point[3]) const;
|
||||
void Gradient(mjtNum grad[3], const mjtNum point[3]) const;
|
||||
|
||||
// a call to this needs to be added to register.cc
|
||||
// 需要在 register.cc 中添加对此函数的调用
|
||||
static void RegisterPlugin();
|
||||
|
||||
// an array of attributes with the same order as in the struct above
|
||||
// 与上述结构体中顺序相同的属性数组
|
||||
mjtNum attribute[MySDFAttribute::nattribute];
|
||||
|
||||
private:
|
||||
MySDF(const mjModel* m, mjData* d, int instance);
|
||||
};
|
||||
```
|
||||
|
||||
|
||||
|
||||
|
||||
|
||||
|
||||
|
||||
|
||||
+38
-63
@@ -1,45 +1,34 @@
|
||||
# Sensor Plugins
|
||||
# 传感器插件(Sensor Plugins)
|
||||
|
||||
Custom sensors implemented as [engine
|
||||
plugins](https://mujoco.readthedocs.io/en/latest/programming/extension.html#engine-plugins).
|
||||
通过[引擎插件](https://mujoco.readthedocs.io/en/latest/programming/extension.html#engine-plugins)实现的自定义传感器。
|
||||
|
||||
- [Touch Grid](#touch-grid)
|
||||
- [Example model](#example-model)
|
||||
- [Illustration of fields-of-view in spherical coordinates](#illustration-of-fields-of-view-in-spherical-coordinates)
|
||||
- [Illustration of foveal deformation](#illustration-of-foveal-deformation)
|
||||
- [Illustration combining resolution, fields-of-view and foveal deformation](#illustration-combining-resolution-fields-of-view-and-foveal-deformation)
|
||||
- [触觉网格(Touch Grid)](#touch-grid)
|
||||
- [示例模型](#example-model)
|
||||
- [球坐标系下的视场角图示](#illustration-of-fields-of-view-in-spherical-coordinates)
|
||||
- [中央凹形变图示](#illustration-of-foveal-deformation)
|
||||
- [结合分辨率、视场角和中央凹形变的综合图示](#illustration-combining-resolution-fields-of-view-and-foveal-deformation)
|
||||
|
||||
- [Touch Stress](#touch-stress)
|
||||
- [Example model with analytical SDF](#example-model-with-analytical-sdf)
|
||||
- [触觉应力(Touch Stress)](#touch-stress)
|
||||
- [解析 SDF 示例模型](#example-model-with-analytical-sdf)
|
||||
|
||||
## [Touch Grid](touch_grid.h)
|
||||
|
||||
This sensor aggregates contact forces into "taxels": a rectangular array of pixel-like elements.
|
||||
该传感器将接触力聚合到“触觉像素(taxels)”中:即类似像素的矩形阵列单元。
|
||||
|
||||
A `touch_grid` sensor is associated with a site and senses contact forces and
|
||||
torques between the site's parent body and all other bodies. The site's frame
|
||||
determines the orientation of the sensor with the same convention used for
|
||||
cameras and lights: the sensor points in the frame's **negative-z** direction,
|
||||
so the x and y axes correspond to horizontal and vertical, respectively.
|
||||
`touch_grid` 传感器与一个 site(位姿点)关联,用于感知该 site 所属的父刚体与所有其他刚体之间的接触力和力矩。site 的坐标系决定了传感器的朝向,采用与相机和光源相同的约定:传感器指向坐标系的 **-z(负 z 轴)**方向,因此 x 轴和 y 轴分别对应水平方向和垂直方向。
|
||||
|
||||
The output of the sensor is a stack of 1 to 6 "touch images" corresponding to forces
|
||||
and torques in the frame of the sensor. Forces and torques are in the in [z, x,
|
||||
y] order, corresponding to the ordering in contact frames: [normal, tangent,
|
||||
tangent] and [torsional, rolling, rolling]. Each "taxel" corresponds to an angular bin
|
||||
in spherical coordinates, and aggregates all the forces occurring inside this bin, which occur
|
||||
between the body in which the sensor's site is defined and any other body.
|
||||
该传感器的输出是 1 到 6 个“触觉图像(touch images)”的堆叠,对应于传感器坐标系中的力和力矩。力和力矩按照 [z, x, y] 顺序排列,对应于接触坐标系中的顺序:[法向, 切向, 切向] 和 [扭转, 滚动, 滚动]。每个“触觉像素(taxel)”对应于球坐标系中的一个角度分桶(angular bin),并聚合该分桶内发生的所有接触力(发生在传感器 site 所属刚体与任何其他刚体之间)。
|
||||
|
||||
The sensor is parametrized by 6 numbers:
|
||||
该传感器由 6 个参数进行参数化:
|
||||
|
||||
1. Number of channels, in the order given above. _positive integer in [1 6]_
|
||||
2. Horizontal resolution. _positive integer_
|
||||
3. Vertical resolution. _positive integer_
|
||||
4. Horizontal field-of-view. _positive float in (0, 180] degrees_
|
||||
5. Vertical field-of-view. _positive float in (0, 90] degrees_
|
||||
6. Foveal deformation. _positive float in [0, 1]_
|
||||
1. 通道数(按照上述顺序):_取值范围为 [1, 6] 的正整数_
|
||||
2. 水平分辨率:_正整数_
|
||||
3. 垂直分辨率:_正整数_
|
||||
4. 水平视场角(FOV):_角度范围在 (0, 180] 度的正浮点数_
|
||||
5. 垂直视场角(FOV):_角度范围在 (0, 90] 度的正浮点数_
|
||||
6. 中央凹形变(Foveal deformation):_取值范围在 [0, 1] 的正浮点数_
|
||||
|
||||
See illustrations below for a visual explanation of the field-of-view and foveal
|
||||
deformation parameters. These parameters are passed as plugin config attributes:
|
||||
有关视场角和中央凹形变参数的可视化解释,请参见下方的图示。这些参数作为插件的配置属性进行传递:
|
||||
|
||||
```xml
|
||||
<mujoco>
|
||||
@@ -58,57 +47,43 @@ deformation parameters. These parameters are passed as plugin config attributes:
|
||||
</mujoco>
|
||||
```
|
||||
|
||||
Note the following:
|
||||
请注意以下事项:
|
||||
|
||||
- The dimensionality of the sensor output is `nchannel * size_x *size_y`.
|
||||
- `objtype="site" objname="touch"` specify that the sensor is associated with a
|
||||
site, and the name of the specific site.
|
||||
- Field-of-view angles are always in degrees, disregarding the `<compiler>`
|
||||
"angle" directive.
|
||||
- 传感器输出的维度为 `nchannel * size_x * size_y`。
|
||||
- `objtype="site" objname="touch"` 指定传感器与 site 关联,以及关联的特定 site 名称。
|
||||
- 视场角始终以“度”为单位,不受 `<compiler>` 中的 "angle" 指令影响。
|
||||
|
||||
### Example model
|
||||
### 示例模型
|
||||
|
||||
<a href="https://youtu.be/0LOJ3WMnqeA" target="_blank">
|
||||
<img src="http://img.youtube.com/vi/0LOJ3WMnqeA/hqdefault.jpg" alt="Watch the video" width="560" height="315"/>
|
||||
<img src="http://img.youtube.com/vi/0LOJ3WMnqeA/hqdefault.jpg" alt="观看视频" width="560" height="315"/>
|
||||
</a>
|
||||
|
||||
See [touch_grid.xml](../../model/plugin/sensor/touch_grid.xml) to play with the model above.
|
||||
请查阅 [touch_grid.xml](../../model/plugin/sensor/touch_grid.xml) 来体验上述模型。
|
||||
|
||||
### Illustration of fields-of-view in spherical coordinates
|
||||
### 球坐标系下的视场角图示
|
||||
|
||||
<img src="images/30-30.png" style="width: 300px;"/>
|
||||
<img src="images/180-30.png" style="width: 300px;"/>
|
||||
<img src="images/180-90.png" style="width: 300px;"/>
|
||||
|
||||
### Illustration of foveal deformation
|
||||
### 中央凹形变图示
|
||||
|
||||

|
||||

|
||||
|
||||
### Illustration combining resolution, fields-of-view and foveal deformation
|
||||
### 结合分辨率、视场角和中央凹形变的综合图示
|
||||
|
||||
[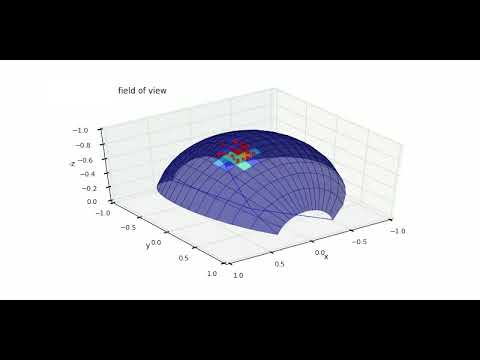](https://www.youtube.com/watch?v=YScjmR8LwQI)
|
||||
[](https://www.youtube.com/watch?v=YScjmR8LwQI)
|
||||
|
||||
## [Touch Stress](touch_stress.h)
|
||||
|
||||
This sensor is based on similar concepts and parametrization as the `touch_grid`,
|
||||
while overcoming some of its limitations. In particular, the `touch_grid` can
|
||||
only provide sparse information, depending on the number of contact points
|
||||
generated. The `touch_stress` sensor can instead generate a high-resolution
|
||||
touch image. In order to do this, it requires a signed distance function (SDF)
|
||||
of the object that is in contact with the sensor. This is handled internally for
|
||||
primitives or it must be declared explicitly in the model using SDF plugins.
|
||||
该传感器基于与 `touch_grid` 相似的概念和参数化设计,同时克服了它的一些局限性。具体而言,`touch_grid` 只能提供稀疏信息(取决于生成的接触点数量)。而 `touch_stress` 传感器可以生成高分辨率的触觉图像。为了实现这一点,它需要与传感器接触的物体的符号距离函数(Signed Distance Function, SDF)。对于基本几何图元(primitives),这会在内部自动处理;或者必须使用 SDF 插件在模型中显式声明。
|
||||
|
||||
There is one important difference with respect to the `touch_grid`: in this case,
|
||||
the force is computed in the local taxel frame and not in the frame of the sensor.
|
||||
This allows for a more intuitive interpretation of normal and tangential stresses,
|
||||
as shown in the images below.
|
||||
与 `touch_grid` 相比有一个重要区别:在此传感器中,力是在局部 taxel 坐标系下计算的,而不是在传感器坐标系下计算的。这使得法向应力和切向应力的物理意义更加直观,如下图所示。
|
||||
|
||||
Note that in this case, the absolute values of the stresses reported by the
|
||||
sensor are unrelated to the contact forces. They are purely based on geometric
|
||||
and kinematic considerations, i.e. the SDF for the normal stress and the sliding
|
||||
velocity for the tangential contributions.
|
||||
请注意,在这种情况下,传感器报告的应力绝对值与接触力无关。它们纯粹基于几何和运动学考量,即法向应力基于 SDF,切向分量基于滑动速度。
|
||||
|
||||
### Example model with analytical SDF
|
||||
### 解析 SDF 示例模型
|
||||
|
||||
```xml
|
||||
<extension>
|
||||
@@ -142,8 +117,8 @@ velocity for the tangential contributions.
|
||||
</sensor>
|
||||
</extension>
|
||||
```
|
||||
The images below show a static sphere over a gear described by an analytic SDF
|
||||
and the same sphere dragged along the x and y axes.
|
||||
|
||||
下图展示了由解析 SDF 描述的齿轮上方的一个静止球体,以及沿 x 轴和 y 轴拖动同一球体时的应力分布:
|
||||
|
||||
<img src="images/normal.png" style="width: 300px;"/>
|
||||
<img src="images/tangential1.png" style="width: 300px;"/>
|
||||
|
||||
Reference in New Issue
Block a user