add chinese
build / setup (compute matrix) (push) Has been cancelled
build / ${{ matrix.label }} (push) Has been cancelled
build / macos-15-arm64-studio (push) Has been cancelled
build / ubuntu-24.04-clang-18-studio (push) Has been cancelled
build / ubuntu-24.04-gcc-14-studio (push) Has been cancelled
build / windows-2025-ninja-studio (push) Has been cancelled
build / ubuntu-24.04-clang-18-wasm (push) Has been cancelled
build / ubuntu-24.04-clang-18-mjx (push) Has been cancelled
This commit is contained in:

+38
-63
@@ -1,45 +1,34 @@
|
||||
# Sensor Plugins
|
||||
# 传感器插件(Sensor Plugins)
|
||||
|
||||
Custom sensors implemented as [engine
|
||||
plugins](https://mujoco.readthedocs.io/en/latest/programming/extension.html#engine-plugins).
|
||||
通过[引擎插件](https://mujoco.readthedocs.io/en/latest/programming/extension.html#engine-plugins)实现的自定义传感器。
|
||||
|
||||
- [Touch Grid](#touch-grid)
|
||||
- [Example model](#example-model)
|
||||
- [Illustration of fields-of-view in spherical coordinates](#illustration-of-fields-of-view-in-spherical-coordinates)
|
||||
- [Illustration of foveal deformation](#illustration-of-foveal-deformation)
|
||||
- [Illustration combining resolution, fields-of-view and foveal deformation](#illustration-combining-resolution-fields-of-view-and-foveal-deformation)
|
||||
- [触觉网格(Touch Grid)](#touch-grid)
|
||||
- [示例模型](#example-model)
|
||||
- [球坐标系下的视场角图示](#illustration-of-fields-of-view-in-spherical-coordinates)
|
||||
- [中央凹形变图示](#illustration-of-foveal-deformation)
|
||||
- [结合分辨率、视场角和中央凹形变的综合图示](#illustration-combining-resolution-fields-of-view-and-foveal-deformation)
|
||||
|
||||
- [Touch Stress](#touch-stress)
|
||||
- [Example model with analytical SDF](#example-model-with-analytical-sdf)
|
||||
- [触觉应力(Touch Stress)](#touch-stress)
|
||||
- [解析 SDF 示例模型](#example-model-with-analytical-sdf)
|
||||
|
||||
## [Touch Grid](touch_grid.h)
|
||||
|
||||
This sensor aggregates contact forces into "taxels": a rectangular array of pixel-like elements.
|
||||
该传感器将接触力聚合到“触觉像素(taxels)”中:即类似像素的矩形阵列单元。
|
||||
|
||||
A `touch_grid` sensor is associated with a site and senses contact forces and
|
||||
torques between the site's parent body and all other bodies. The site's frame
|
||||
determines the orientation of the sensor with the same convention used for
|
||||
cameras and lights: the sensor points in the frame's **negative-z** direction,
|
||||
so the x and y axes correspond to horizontal and vertical, respectively.
|
||||
`touch_grid` 传感器与一个 site(位姿点)关联,用于感知该 site 所属的父刚体与所有其他刚体之间的接触力和力矩。site 的坐标系决定了传感器的朝向,采用与相机和光源相同的约定:传感器指向坐标系的 **-z(负 z 轴)**方向,因此 x 轴和 y 轴分别对应水平方向和垂直方向。
|
||||
|
||||
The output of the sensor is a stack of 1 to 6 "touch images" corresponding to forces
|
||||
and torques in the frame of the sensor. Forces and torques are in the in [z, x,
|
||||
y] order, corresponding to the ordering in contact frames: [normal, tangent,
|
||||
tangent] and [torsional, rolling, rolling]. Each "taxel" corresponds to an angular bin
|
||||
in spherical coordinates, and aggregates all the forces occurring inside this bin, which occur
|
||||
between the body in which the sensor's site is defined and any other body.
|
||||
该传感器的输出是 1 到 6 个“触觉图像(touch images)”的堆叠,对应于传感器坐标系中的力和力矩。力和力矩按照 [z, x, y] 顺序排列,对应于接触坐标系中的顺序:[法向, 切向, 切向] 和 [扭转, 滚动, 滚动]。每个“触觉像素(taxel)”对应于球坐标系中的一个角度分桶(angular bin),并聚合该分桶内发生的所有接触力(发生在传感器 site 所属刚体与任何其他刚体之间)。
|
||||
|
||||
The sensor is parametrized by 6 numbers:
|
||||
该传感器由 6 个参数进行参数化:
|
||||
|
||||
1. Number of channels, in the order given above. _positive integer in [1 6]_
|
||||
2. Horizontal resolution. _positive integer_
|
||||
3. Vertical resolution. _positive integer_
|
||||
4. Horizontal field-of-view. _positive float in (0, 180] degrees_
|
||||
5. Vertical field-of-view. _positive float in (0, 90] degrees_
|
||||
6. Foveal deformation. _positive float in [0, 1]_
|
||||
1. 通道数(按照上述顺序):_取值范围为 [1, 6] 的正整数_
|
||||
2. 水平分辨率:_正整数_
|
||||
3. 垂直分辨率:_正整数_
|
||||
4. 水平视场角(FOV):_角度范围在 (0, 180] 度的正浮点数_
|
||||
5. 垂直视场角(FOV):_角度范围在 (0, 90] 度的正浮点数_
|
||||
6. 中央凹形变(Foveal deformation):_取值范围在 [0, 1] 的正浮点数_
|
||||
|
||||
See illustrations below for a visual explanation of the field-of-view and foveal
|
||||
deformation parameters. These parameters are passed as plugin config attributes:
|
||||
有关视场角和中央凹形变参数的可视化解释,请参见下方的图示。这些参数作为插件的配置属性进行传递:
|
||||
|
||||
```xml
|
||||
<mujoco>
|
||||
@@ -58,57 +47,43 @@ deformation parameters. These parameters are passed as plugin config attributes:
|
||||
</mujoco>
|
||||
```
|
||||
|
||||
Note the following:
|
||||
请注意以下事项:
|
||||
|
||||
- The dimensionality of the sensor output is `nchannel * size_x *size_y`.
|
||||
- `objtype="site" objname="touch"` specify that the sensor is associated with a
|
||||
site, and the name of the specific site.
|
||||
- Field-of-view angles are always in degrees, disregarding the `<compiler>`
|
||||
"angle" directive.
|
||||
- 传感器输出的维度为 `nchannel * size_x * size_y`。
|
||||
- `objtype="site" objname="touch"` 指定传感器与 site 关联,以及关联的特定 site 名称。
|
||||
- 视场角始终以“度”为单位,不受 `<compiler>` 中的 "angle" 指令影响。
|
||||
|
||||
### Example model
|
||||
### 示例模型
|
||||
|
||||
<a href="https://youtu.be/0LOJ3WMnqeA" target="_blank">
|
||||
<img src="http://img.youtube.com/vi/0LOJ3WMnqeA/hqdefault.jpg" alt="Watch the video" width="560" height="315"/>
|
||||
<img src="http://img.youtube.com/vi/0LOJ3WMnqeA/hqdefault.jpg" alt="观看视频" width="560" height="315"/>
|
||||
</a>
|
||||
|
||||
See [touch_grid.xml](../../model/plugin/sensor/touch_grid.xml) to play with the model above.
|
||||
请查阅 [touch_grid.xml](../../model/plugin/sensor/touch_grid.xml) 来体验上述模型。
|
||||
|
||||
### Illustration of fields-of-view in spherical coordinates
|
||||
### 球坐标系下的视场角图示
|
||||
|
||||
<img src="images/30-30.png" style="width: 300px;"/>
|
||||
<img src="images/180-30.png" style="width: 300px;"/>
|
||||
<img src="images/180-90.png" style="width: 300px;"/>
|
||||
|
||||
### Illustration of foveal deformation
|
||||
### 中央凹形变图示
|
||||
|
||||

|
||||

|
||||
|
||||
### Illustration combining resolution, fields-of-view and foveal deformation
|
||||
### 结合分辨率、视场角和中央凹形变的综合图示
|
||||
|
||||
[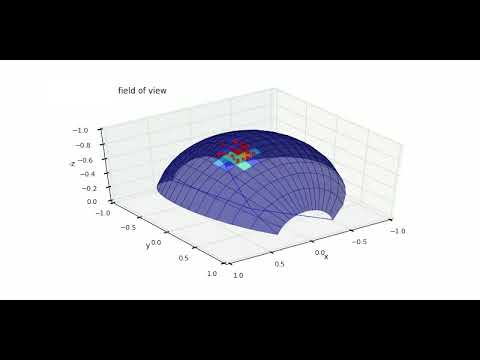](https://www.youtube.com/watch?v=YScjmR8LwQI)
|
||||
[](https://www.youtube.com/watch?v=YScjmR8LwQI)
|
||||
|
||||
## [Touch Stress](touch_stress.h)
|
||||
|
||||
This sensor is based on similar concepts and parametrization as the `touch_grid`,
|
||||
while overcoming some of its limitations. In particular, the `touch_grid` can
|
||||
only provide sparse information, depending on the number of contact points
|
||||
generated. The `touch_stress` sensor can instead generate a high-resolution
|
||||
touch image. In order to do this, it requires a signed distance function (SDF)
|
||||
of the object that is in contact with the sensor. This is handled internally for
|
||||
primitives or it must be declared explicitly in the model using SDF plugins.
|
||||
该传感器基于与 `touch_grid` 相似的概念和参数化设计,同时克服了它的一些局限性。具体而言,`touch_grid` 只能提供稀疏信息(取决于生成的接触点数量)。而 `touch_stress` 传感器可以生成高分辨率的触觉图像。为了实现这一点,它需要与传感器接触的物体的符号距离函数(Signed Distance Function, SDF)。对于基本几何图元(primitives),这会在内部自动处理;或者必须使用 SDF 插件在模型中显式声明。
|
||||
|
||||
There is one important difference with respect to the `touch_grid`: in this case,
|
||||
the force is computed in the local taxel frame and not in the frame of the sensor.
|
||||
This allows for a more intuitive interpretation of normal and tangential stresses,
|
||||
as shown in the images below.
|
||||
与 `touch_grid` 相比有一个重要区别:在此传感器中,力是在局部 taxel 坐标系下计算的,而不是在传感器坐标系下计算的。这使得法向应力和切向应力的物理意义更加直观,如下图所示。
|
||||
|
||||
Note that in this case, the absolute values of the stresses reported by the
|
||||
sensor are unrelated to the contact forces. They are purely based on geometric
|
||||
and kinematic considerations, i.e. the SDF for the normal stress and the sliding
|
||||
velocity for the tangential contributions.
|
||||
请注意,在这种情况下,传感器报告的应力绝对值与接触力无关。它们纯粹基于几何和运动学考量,即法向应力基于 SDF,切向分量基于滑动速度。
|
||||
|
||||
### Example model with analytical SDF
|
||||
### 解析 SDF 示例模型
|
||||
|
||||
```xml
|
||||
<extension>
|
||||
@@ -142,8 +117,8 @@ velocity for the tangential contributions.
|
||||
</sensor>
|
||||
</extension>
|
||||
```
|
||||
The images below show a static sphere over a gear described by an analytic SDF
|
||||
and the same sphere dragged along the x and y axes.
|
||||
|
||||
下图展示了由解析 SDF 描述的齿轮上方的一个静止球体,以及沿 x 轴和 y 轴拖动同一球体时的应力分布:
|
||||
|
||||
<img src="images/normal.png" style="width: 300px;"/>
|
||||
<img src="images/tangential1.png" style="width: 300px;"/>
|
||||
|
||||
Reference in New Issue
Block a user