Alessio Quaglino
e59720833e
PiperOrigin-RevId: 528783871
Change-Id: Icf3d060116826b01f68c9818a5153be4ce9511b0
3.5 KiB
Sensor Plugins
Custom sensors implemented as engine plugins.
Touch Grid
This sensor aggregates contact forces into "taxels": a rectangular array of pixel-like elements.
A touch_grid sensor is associated with a site and senses contact forces and
torques between the site's parent body and all other bodies. The site's frame
determines the orientation of the sensor with the same convention used for
cameras and lights: the sensor points in the frame's negative-z direction,
so the x and y axes correspond to horizontal and vertical, respectively.
The output of the sensor is a stack of 1 to 6 "touch images" corresponding to forces and torques in the frame of the sensor. Forces and torques are in the in [z, x, y] order, corresponding to the ordering in contact frames: [normal, tangent, tangent] and [torsional, rolling, rolling]. Each "taxel" corresponds to an angular bin in spherical coordinates, and aggregates all the forces occuring inside this bin, which occur between the body in which the sensor's site is defined and any other body.
The sensor is parametrized by 6 numbers:
- Number of channels, in the order given above. positive integer in [1 6]
- Horizontal resolution. positive integer
- Vertical resolution. positive integer
- Horizontal field-of-view. positive float in (0, 180] degrees
- Vertical field-of-view. positive float in (0, 90] degrees
- Foveal deformation. positive float in [0, 1]
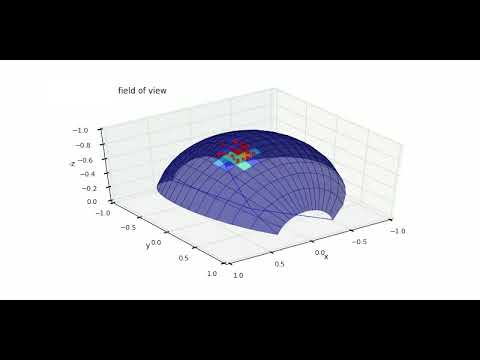
See illustrations below for a visual explanation of the field-of-view and foveal deformation parameters. These parameters are passed as plugin config attributes:
<mujoco>
  <extension>
    <plugin plugin="mujoco.sensor.touch_grid"/>
  </extension>
  ...
  <sensor>
    <plugin name="touch" plugin="mujoco.sensor.touch_grid" objtype="site" objname="touch">
      <config key="nchannel" value="3"/>
      <config key="size" value="7 7"/>
      <config key="fov" value="45 45"/>
      <config key="gamma" value="0"/>
    </plugin>
  </sensor>
</mujoco>
Note the following:
- The dimensionality of the sensor output is
nchannel * size_x *size_y. objtype="site" objname="touch"specify that the sensor is associated with a site, and the name of the specific site.- Field-of-view angles are always in degrees, disregarding the
<compiler>"angle" directive.
Example model
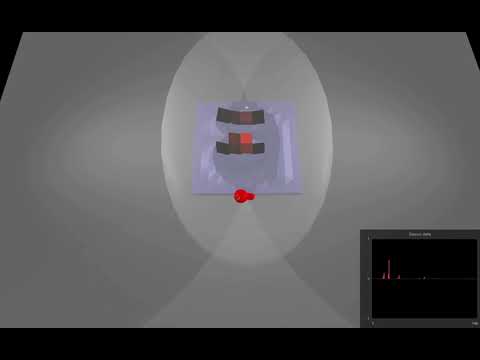
See touch_grid.xml to play with the model above.
Illustration of fields-of-view in spherical coordinates


Illustration of foveal deformation

Illustration combining resolution, fields-of-view and foveal deformation