Sam Haves
9e150fe82c
This will fetch and call the build_usd.py build helper for OpenUSD and build within the MuJoCo _deps folder. Simplifying the build process for MuJoCo with USD. Users can still provide their own USD build, but must now do so via pxr_DIR.

PiperOrigin-RevId: 846735578
Change-Id: I0da7eb2da6465e2d518084340e762bf370adb6d5
Simulate App
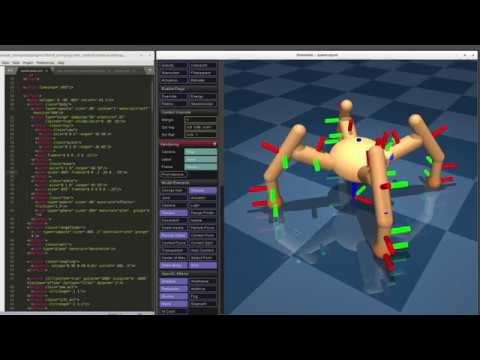
simulate is a fully-featured interactive application for MuJoCo. It opens an
OpenGL window using the platform-independent GLFW library, and renders the
simulation state in it. There is built-in help, simulation statistics, profiler,
sensor data plots. The model file can be specified as a command-line argument,
or loaded at runtime using drag-and-drop functionality. Below is a
screen-capture of simulate in action: