Add 3x3x3 cube to model collection.
PiperOrigin-RevId: 531224451
Change-Id: Ibdfe5b89a5b2895500265199906a364768d606f0
 Kevin Zakka
Copybara-Service
@@ -46,6 +46,17 @@ General
|
||||
1, & 1 \le & x \qquad
|
||||
\end{cases}
|
||||
|
||||
|
||||
.. youtube:: ZppeDArq6AU
|
||||
:align: right
|
||||
:width: 240px
|
||||
|
||||
Models
|
||||
^^^^^^
|
||||
|
||||
- Added `3x3x3 cube <https://github.com/deepmind/mujoco/blob/main/model/cube/cube_3x3x3.xml>`__ example model. See
|
||||
`README <https://github.com/deepmind/mujoco/blob/main/model/cube/README.md>`__ for details.
|
||||
|
||||
Version 2.3.5 (April 25, 2023)
|
||||
------------------------------
|
||||
|
||||
|
||||
@@ -0,0 +1,7 @@
|
||||
# Cube
|
||||
|
||||
This model was contributed by Kevin Zakka. For details regarding its creation, see the associated [repository](https://github.com/kevinzakka/mujoco_cube).
|
||||
|
||||
Click the video below to see a user interacting with the cube:
|
||||
|
||||
[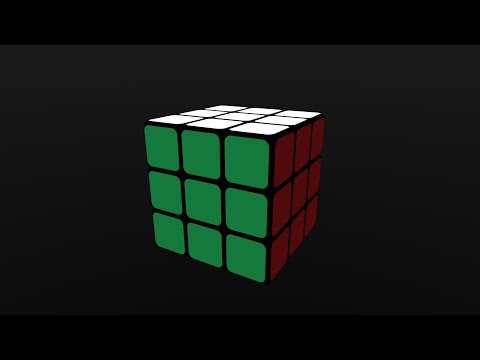](https://www.youtube.com/watch?v=ZppeDArq6AU)
|
||||

|
After Width: | Height: | Size: 3.0 KiB |

|
After Width: | Height: | Size: 3.3 KiB |

|
After Width: | Height: | Size: 3.5 KiB |

|
After Width: | Height: | Size: 3.5 KiB |

|
After Width: | Height: | Size: 3.3 KiB |

|
After Width: | Height: | Size: 3.5 KiB |

|
After Width: | Height: | Size: 3.5 KiB |

|
After Width: | Height: | Size: 3.3 KiB |

|
After Width: | Height: | Size: 3.3 KiB |

|
After Width: | Height: | Size: 3.0 KiB |

|
After Width: | Height: | Size: 3.3 KiB |

|
After Width: | Height: | Size: 3.5 KiB |

|
After Width: | Height: | Size: 3.5 KiB |

|
After Width: | Height: | Size: 3.3 KiB |

|
After Width: | Height: | Size: 3.5 KiB |

|
After Width: | Height: | Size: 3.5 KiB |

|
After Width: | Height: | Size: 3.3 KiB |

|
After Width: | Height: | Size: 3.3 KiB |

|
After Width: | Height: | Size: 3.0 KiB |

|
After Width: | Height: | Size: 3.3 KiB |

|
After Width: | Height: | Size: 3.3 KiB |

|
After Width: | Height: | Size: 3.3 KiB |

|
After Width: | Height: | Size: 3.0 KiB |

|
After Width: | Height: | Size: 3.3 KiB |

|
After Width: | Height: | Size: 3.3 KiB |

|
After Width: | Height: | Size: 3.0 KiB |

|
After Width: | Height: | Size: 3.0 KiB |
@@ -0,0 +1,265 @@
|
||||
<mujoco model="Cube 3x3x3">
|
||||
<compiler autolimits="true" angle="radian" texturedir="assets"/>
|
||||
|
||||
<option timestep="0.01" integrator="implicitfast"/>
|
||||
|
||||
<size memory="600K"/>
|
||||
|
||||
<visual>
|
||||
<global azimuth="180" elevation="-20"/>
|
||||
<headlight ambient="0.3 0.3 0.3" diffuse="0.6 0.6 0.6" specular="0 0 0"/>
|
||||
</visual>
|
||||
|
||||
<statistic extent="0.1"/>
|
||||
|
||||
<default>
|
||||
<geom mass="0.00253704"/>
|
||||
<motor ctrlrange="-0.05 0.05"/>
|
||||
<default class="cubelet">
|
||||
<joint type="ball" armature="0.0001" damping="0.0005" frictionloss="0.0005"/>
|
||||
<geom type="mesh" condim="1" margin="-0.001" mesh="cubelet"/>
|
||||
</default>
|
||||
<default class="core">
|
||||
<geom type="sphere" contype="0" conaffinity="0" group="4" size="0.01"/>
|
||||
</default>
|
||||
</default>
|
||||
|
||||
<asset>
|
||||
<texture type="skybox" builtin="gradient" rgb1="0.2 0.2 0.2" rgb2="0 0 0" width="512" height="512"/>
|
||||
<texture file="white.png" gridsize="3 4" gridlayout=".....F......" rgb1="0 0 0"/>
|
||||
<texture file="yellow.png" gridsize="3 4" gridlayout=".....B......" rgb1="0 0 0"/>
|
||||
<texture file="red.png" gridsize="3 4" gridlayout=".....D......" rgb1="0 0 0"/>
|
||||
<texture file="orange.png" gridsize="3 4" gridlayout=".....U......" rgb1="0 0 0"/>
|
||||
<texture file="blue.png" gridsize="3 4" gridlayout=".....R......" rgb1="0 0 0"/>
|
||||
<texture file="green.png" gridsize="3 4" gridlayout=".....L......" rgb1="0 0 0"/>
|
||||
<texture file="red_white.png" gridsize="3 4" gridlayout=".....DF....." rgb1="0 0 0"/>
|
||||
<texture file="orange_white.png" gridsize="3 4" gridlayout=".....UF....." rgb1="0 0 0"/>
|
||||
<texture file="blue_white.png" gridsize="3 4" gridlayout=".....RF....." rgb1="0 0 0"/>
|
||||
<texture file="green_white.png" gridsize="3 4" gridlayout=".....LF....." rgb1="0 0 0"/>
|
||||
<texture file="red_yellow.png" gridsize="3 4" gridlayout=".....DB....." rgb1="0 0 0"/>
|
||||
<texture file="orange_yellow.png" gridsize="3 4" gridlayout=".....UB....." rgb1="0 0 0"/>
|
||||
<texture file="blue_yellow.png" gridsize="3 4" gridlayout=".....RB....." rgb1="0 0 0"/>
|
||||
<texture file="green_yellow.png" gridsize="3 4" gridlayout=".....LB....." rgb1="0 0 0"/>
|
||||
<texture file="orange_red.png" gridsize="3 4" gridlayout=".....UD....." rgb1="0 0 0"/>
|
||||
<texture file="blue_red.png" gridsize="3 4" gridlayout=".....RD....." rgb1="0 0 0"/>
|
||||
<texture file="green_red.png" gridsize="3 4" gridlayout=".....LD....." rgb1="0 0 0"/>
|
||||
<texture file="blue_orange.png" gridsize="3 4" gridlayout=".....RU....." rgb1="0 0 0"/>
|
||||
<texture file="green_orange.png" gridsize="3 4" gridlayout=".....LU....." rgb1="0 0 0"/>
|
||||
<texture file="blue_red_white.png" gridsize="3 4" gridlayout=".....RDF...." rgb1="0 0 0"/>
|
||||
<texture file="green_red_white.png" gridsize="3 4" gridlayout=".....LDF...." rgb1="0 0 0"/>
|
||||
<texture file="blue_orange_white.png" gridsize="3 4" gridlayout=".....RUF...." rgb1="0 0 0"/>
|
||||
<texture file="green_orange_white.png" gridsize="3 4" gridlayout=".....LUF...." rgb1="0 0 0"/>
|
||||
<texture file="blue_red_yellow.png" gridsize="3 4" gridlayout=".....RDB...." rgb1="0 0 0"/>
|
||||
<texture file="green_red_yellow.png" gridsize="3 4" gridlayout=".....LDB...." rgb1="0 0 0"/>
|
||||
<texture file="blue_orange_yellow.png" gridsize="3 4" gridlayout=".....RUB...." rgb1="0 0 0"/>
|
||||
<texture file="green_orange_yellow.png" gridsize="3 4" gridlayout=".....LUB...." rgb1="0 0 0"/>
|
||||
<material name="white" texture="white"/>
|
||||
<material name="yellow" texture="yellow"/>
|
||||
<material name="red" texture="red"/>
|
||||
<material name="orange" texture="orange"/>
|
||||
<material name="blue" texture="blue"/>
|
||||
<material name="green" texture="green"/>
|
||||
<material name="red_white" texture="red_white"/>
|
||||
<material name="orange_white" texture="orange_white"/>
|
||||
<material name="blue_white" texture="blue_white"/>
|
||||
<material name="green_white" texture="green_white"/>
|
||||
<material name="red_yellow" texture="red_yellow"/>
|
||||
<material name="orange_yellow" texture="orange_yellow"/>
|
||||
<material name="blue_yellow" texture="blue_yellow"/>
|
||||
<material name="green_yellow" texture="green_yellow"/>
|
||||
<material name="orange_red" texture="orange_red"/>
|
||||
<material name="blue_red" texture="blue_red"/>
|
||||
<material name="green_red" texture="green_red"/>
|
||||
<material name="blue_orange" texture="blue_orange"/>
|
||||
<material name="green_orange" texture="green_orange"/>
|
||||
<material name="blue_red_white" texture="blue_red_white"/>
|
||||
<material name="green_red_white" texture="green_red_white"/>
|
||||
<material name="blue_orange_white" texture="blue_orange_white"/>
|
||||
<material name="green_orange_white" texture="green_orange_white"/>
|
||||
<material name="blue_red_yellow" texture="blue_red_yellow"/>
|
||||
<material name="green_red_yellow" texture="green_red_yellow"/>
|
||||
<material name="blue_orange_yellow" texture="blue_orange_yellow"/>
|
||||
<material name="green_orange_yellow" texture="green_orange_yellow"/>
|
||||
<mesh name="cubelet"
|
||||
vertex="0.0085 -0.01 0.0085 -0.0085 -0.01 -0.0085 0.0085 -0.01 -0.0085
|
||||
0.01 0.0085 0.0085 0.01 -0.0085 -0.0085 0.01 0.0085 -0.0085
|
||||
-0.0085 0.0085 0.01 0.0085 -0.0085 0.01 0.0085 0.0085 0.01
|
||||
-0.01 -0.0085 0.0085 -0.01 0.0085 -0.0085 -0.01 -0.0085 -0.0085
|
||||
-0.0085 0.01 0.0085 0.0085 0.01 -0.0085 -0.0085 0.01 -0.0085
|
||||
-0.0085 -0.0085 -0.01 -0.0085 -0.01 0.0085 -0.0085 -0.0085 0.01
|
||||
-0.0085 0.0085 -0.01 -0.01 0.0085 0.0085 0.0085 -0.0085 -0.01
|
||||
0.01 -0.0085 0.0085 0.0085 0.0085 -0.01 0.0085 0.01 0.0085"/>
|
||||
</asset>
|
||||
|
||||
<worldbody>
|
||||
<light pos="0 0 1"/>
|
||||
<body name="core" childclass="cubelet">
|
||||
<geom class="core"/>
|
||||
<body name="pX">
|
||||
<joint name="pX" type="hinge" axis="1 0 0"/>
|
||||
<body name="mesh_pX" pos="0.01905 0 0">
|
||||
<geom material="red"/>
|
||||
</body>
|
||||
</body>
|
||||
<body name="nX">
|
||||
<joint name="nX" type="hinge" axis="-1 0 0"/>
|
||||
<body name="mesh_nX" pos="-0.01905 0 0">
|
||||
<geom material="orange"/>
|
||||
</body>
|
||||
</body>
|
||||
<body name="pY">
|
||||
<joint name="pY" type="hinge" axis="0 1 0"/>
|
||||
<body name="mesh_pY" pos="0 0.01905 0">
|
||||
<geom material="blue"/>
|
||||
</body>
|
||||
</body>
|
||||
<body name="nY">
|
||||
<joint name="nY" type="hinge" axis="0 -1 0"/>
|
||||
<body name="mesh_nY" pos="0 -0.01905 0">
|
||||
<geom material="green"/>
|
||||
</body>
|
||||
</body>
|
||||
<body name="pZ">
|
||||
<joint name="pZ" type="hinge" axis="0 0 1"/>
|
||||
<body name="mesh_pZ" pos="0 0 0.01905">
|
||||
<geom material="white"/>
|
||||
</body>
|
||||
</body>
|
||||
<body name="nZ">
|
||||
<joint name="nZ" type="hinge" axis="0 0 -1"/>
|
||||
<body name="mesh_nZ" pos="0 0 -0.01905">
|
||||
<geom material="yellow"/>
|
||||
</body>
|
||||
</body>
|
||||
<body name="pX_pY">
|
||||
<joint name="pX_pY"/>
|
||||
<body name="mesh_pX_pY" pos="0.01905 0.01905 0">
|
||||
<geom material="blue_red"/>
|
||||
</body>
|
||||
</body>
|
||||
<body name="nY_pX">
|
||||
<joint name="nY_pX"/>
|
||||
<body name="mesh_nY_pX" pos="0.01905 -0.01905 0">
|
||||
<geom material="green_red"/>
|
||||
</body>
|
||||
</body>
|
||||
<body name="pX_pZ">
|
||||
<joint name="pX_pZ"/>
|
||||
<body name="mesh_pX_pZ" pos="0.01905 0 0.01905">
|
||||
<geom material="red_white"/>
|
||||
</body>
|
||||
</body>
|
||||
<body name="nZ_pX">
|
||||
<joint name="nZ_pX"/>
|
||||
<body name="mesh_nZ_pX" pos="0.01905 0 -0.01905">
|
||||
<geom material="red_yellow"/>
|
||||
</body>
|
||||
</body>
|
||||
<body name="nX_pY">
|
||||
<joint name="nX_pY"/>
|
||||
<body name="mesh_nX_pY" pos="-0.01905 0.01905 0">
|
||||
<geom material="blue_orange"/>
|
||||
</body>
|
||||
</body>
|
||||
<body name="nX_nY">
|
||||
<joint name="nX_nY"/>
|
||||
<body name="mesh_nX_nY" pos="-0.01905 -0.01905 0">
|
||||
<geom material="green_orange"/>
|
||||
</body>
|
||||
</body>
|
||||
<body name="nX_pZ">
|
||||
<joint name="nX_pZ"/>
|
||||
<body name="mesh_nX_pZ" pos="-0.01905 0 0.01905">
|
||||
<geom material="orange_white"/>
|
||||
</body>
|
||||
</body>
|
||||
<body name="nX_nZ">
|
||||
<joint name="nX_nZ"/>
|
||||
<body name="mesh_nX_nZ" pos="-0.01905 0 -0.01905">
|
||||
<geom material="orange_yellow"/>
|
||||
</body>
|
||||
</body>
|
||||
<body name="pY_pZ">
|
||||
<joint name="pY_pZ"/>
|
||||
<body name="mesh_pY_pZ" pos="0 0.01905 0.01905">
|
||||
<geom material="blue_white"/>
|
||||
</body>
|
||||
</body>
|
||||
<body name="nZ_pY">
|
||||
<joint name="nZ_pY"/>
|
||||
<body name="mesh_nZ_pY" pos="0 0.01905 -0.01905">
|
||||
<geom material="blue_yellow"/>
|
||||
</body>
|
||||
</body>
|
||||
<body name="nY_pZ">
|
||||
<joint name="nY_pZ"/>
|
||||
<body name="mesh_nY_pZ" pos="0 -0.01905 0.01905">
|
||||
<geom material="green_white"/>
|
||||
</body>
|
||||
</body>
|
||||
<body name="nY_nZ">
|
||||
<joint name="nY_nZ"/>
|
||||
<body name="mesh_nY_nZ" pos="0 -0.01905 -0.01905">
|
||||
<geom material="green_yellow"/>
|
||||
</body>
|
||||
</body>
|
||||
<body name="pX_pY_pZ">
|
||||
<joint name="pX_pY_pZ"/>
|
||||
<body name="mesh_pX_pY_pZ" pos="0.01905 0.01905 0.01905">
|
||||
<geom material="blue_red_white"/>
|
||||
</body>
|
||||
</body>
|
||||
<body name="nZ_pX_pY">
|
||||
<joint name="nZ_pX_pY"/>
|
||||
<body name="mesh_nZ_pX_pY" pos="0.01905 0.01905 -0.01905">
|
||||
<geom material="blue_red_yellow"/>
|
||||
</body>
|
||||
</body>
|
||||
<body name="nY_pX_pZ">
|
||||
<joint name="nY_pX_pZ"/>
|
||||
<body name="mesh_nY_pX_pZ" pos="0.01905 -0.01905 0.01905">
|
||||
<geom material="green_red_white"/>
|
||||
</body>
|
||||
</body>
|
||||
<body name="nY_nZ_pX">
|
||||
<joint name="nY_nZ_pX"/>
|
||||
<body name="mesh_nY_nZ_pX" pos="0.01905 -0.01905 -0.01905">
|
||||
<geom material="green_red_yellow"/>
|
||||
</body>
|
||||
</body>
|
||||
<body name="nX_pY_pZ">
|
||||
<joint name="nX_pY_pZ"/>
|
||||
<body name="mesh_nX_pY_pZ" pos="-0.01905 0.01905 0.01905">
|
||||
<geom material="blue_orange_white"/>
|
||||
</body>
|
||||
</body>
|
||||
<body name="nX_nZ_pY">
|
||||
<joint name="nX_nZ_pY"/>
|
||||
<body name="mesh_nX_nZ_pY" pos="-0.01905 0.01905 -0.01905">
|
||||
<geom material="blue_orange_yellow"/>
|
||||
</body>
|
||||
</body>
|
||||
<body name="nX_nY_pZ">
|
||||
<joint name="nX_nY_pZ"/>
|
||||
<body name="mesh_nX_nY_pZ" pos="-0.01905 -0.01905 0.01905">
|
||||
<geom material="green_orange_white"/>
|
||||
</body>
|
||||
</body>
|
||||
<body name="nX_nY_nZ">
|
||||
<joint name="nX_nY_nZ"/>
|
||||
<body name="mesh_nX_nY_nZ" pos="-0.01905 -0.01905 -0.01905">
|
||||
<geom material="green_orange_yellow"/>
|
||||
</body>
|
||||
</body>
|
||||
</body>
|
||||
</worldbody>
|
||||
|
||||
<actuator>
|
||||
<motor name="red" joint="pX"/>
|
||||
<motor name="orange" joint="nX"/>
|
||||
<motor name="blue" joint="pY"/>
|
||||
<motor name="green" joint="nY"/>
|
||||
<motor name="white" joint="pZ"/>
|
||||
<motor name="yellow" joint="nZ"/>
|
||||
</actuator>
|
||||
</mujoco>
|
||||