 Yuval Tassa
b397b3123e
PiperOrigin-RevId: 527512624
Change-Id: I0f316eb6eb2c52472abbec484e5538b66ba2e82e
75 lines
2.9 KiB
Markdown
75 lines
2.9 KiB
Markdown
# Sensor Plugins
|
|
|
|
Custom sensors implemented as [engine plugins](https://mujoco.readthedocs.io/en/latest/programming/extension.html#engine-plugins).
|
|
|
|
## Touch Grid
|
|
|
|
This sensor aggregates contact forces into "taxels": a rectangular array of pixel-like elements.
|
|
|
|
|
|
A `touch grid` sensor is associated with a site and senses contact forces and
|
|
torques between the site's parent body and all other bodies. The site's frame
|
|
determines the orientation of the sensor with the same convention used for
|
|
cameras and lights: the sensor points in the frame's **negative-z** direction,
|
|
so the x and y axes correspond to horizontal and vertical, respectively.
|
|
|
|
The output of the sensor is a stack of 1 to 6 "touch images" corresponding to forces
|
|
and torques in the frame of the sensor. Forces and torques are in the in [z, x,
|
|
y] order, corresponding to the ordering in contact frames: [normal, tangent,
|
|
tangent] and [torsional, rolling, rolling]. Each "taxel" codderponds to an angular bin
|
|
in spherical coordinates, and aggregates all the forces occuring inside this bin, which occur
|
|
between the body in which the sensor's site is defined and any other body.
|
|
|
|
The sensor is parametrized by 6 numbers:
|
|
|
|
1. Number of channels, in the order given above. _positive integer in [1 6]_
|
|
2. Horizontal resolution. _positive integer_
|
|
3. Vertical resolution. _positive integer_
|
|
4. Horizontal field-of-view. _positive float in (0, 180] degrees_
|
|
5. Vertical field-of-view. _positive float in (0, 90] degrees_
|
|
6. Foveal deformation. _positive float in [0, 1]_
|
|
|
|
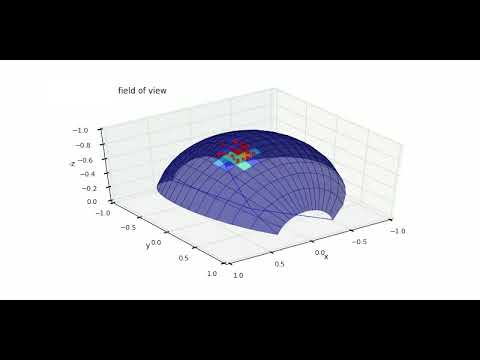
See illustrations below for a visual explanation of the field-of-view and foveal
|
|
deformation parameters. These parameters are passed as plugin config attributes:
|
|
|
|
```xml
|
|
<mujoco>
|
|
<extension>
|
|
<plugin plugin="mujoco.sensor.touch_grid"/>
|
|
</extension>
|
|
...
|
|
<sensor>
|
|
<plugin name="touch" plugin="mujoco.sensor.touch_grid" objtype="site" objname="touch">
|
|
<config key="nchannel" value="3"/>
|
|
<config key="size_x" value="7"/>
|
|
<config key="size_y" value="7"/>
|
|
<config key="fov_x" value="45"/>
|
|
<config key="fov_y" value="45"/>
|
|
<config key="gamma" value="0"/>
|
|
</plugin>
|
|
</sensor>
|
|
</mujoco>
|
|
```
|
|
|
|
Note the following:
|
|
|
|
- The dimensionality of the sensor output is `nchannel * size_x *size_y`.
|
|
- `objtype="site" objname="touch"` specify that the sensor is associated with
|
|
a site, and the name of the specific site.
|
|
- Field-of-view angles are always in degrees, disregarding the `<compiler>`
|
|
"angle" directive.
|
|
|
|
### Illustration of fields-of-view in spherical coordinates:
|
|
|
|
<img src="images/30-30.png" style="width: 300px;"/>
|
|
<img src="images/180-30.png" style="width: 300px;"/>
|
|
<img src="images/180-90.png" style="width: 300px;"/>
|
|
|
|
### Illustration of foveal deformation:
|
|
|
|

|
|
|
|
### Illustration combining resolution, fields-of-view and foveal deformation:
|
|
|
|
[](https://www.youtube.com/watch?v=YScjmR8LwQI)
|